DEPRO SLS: Flexible ROV deployment
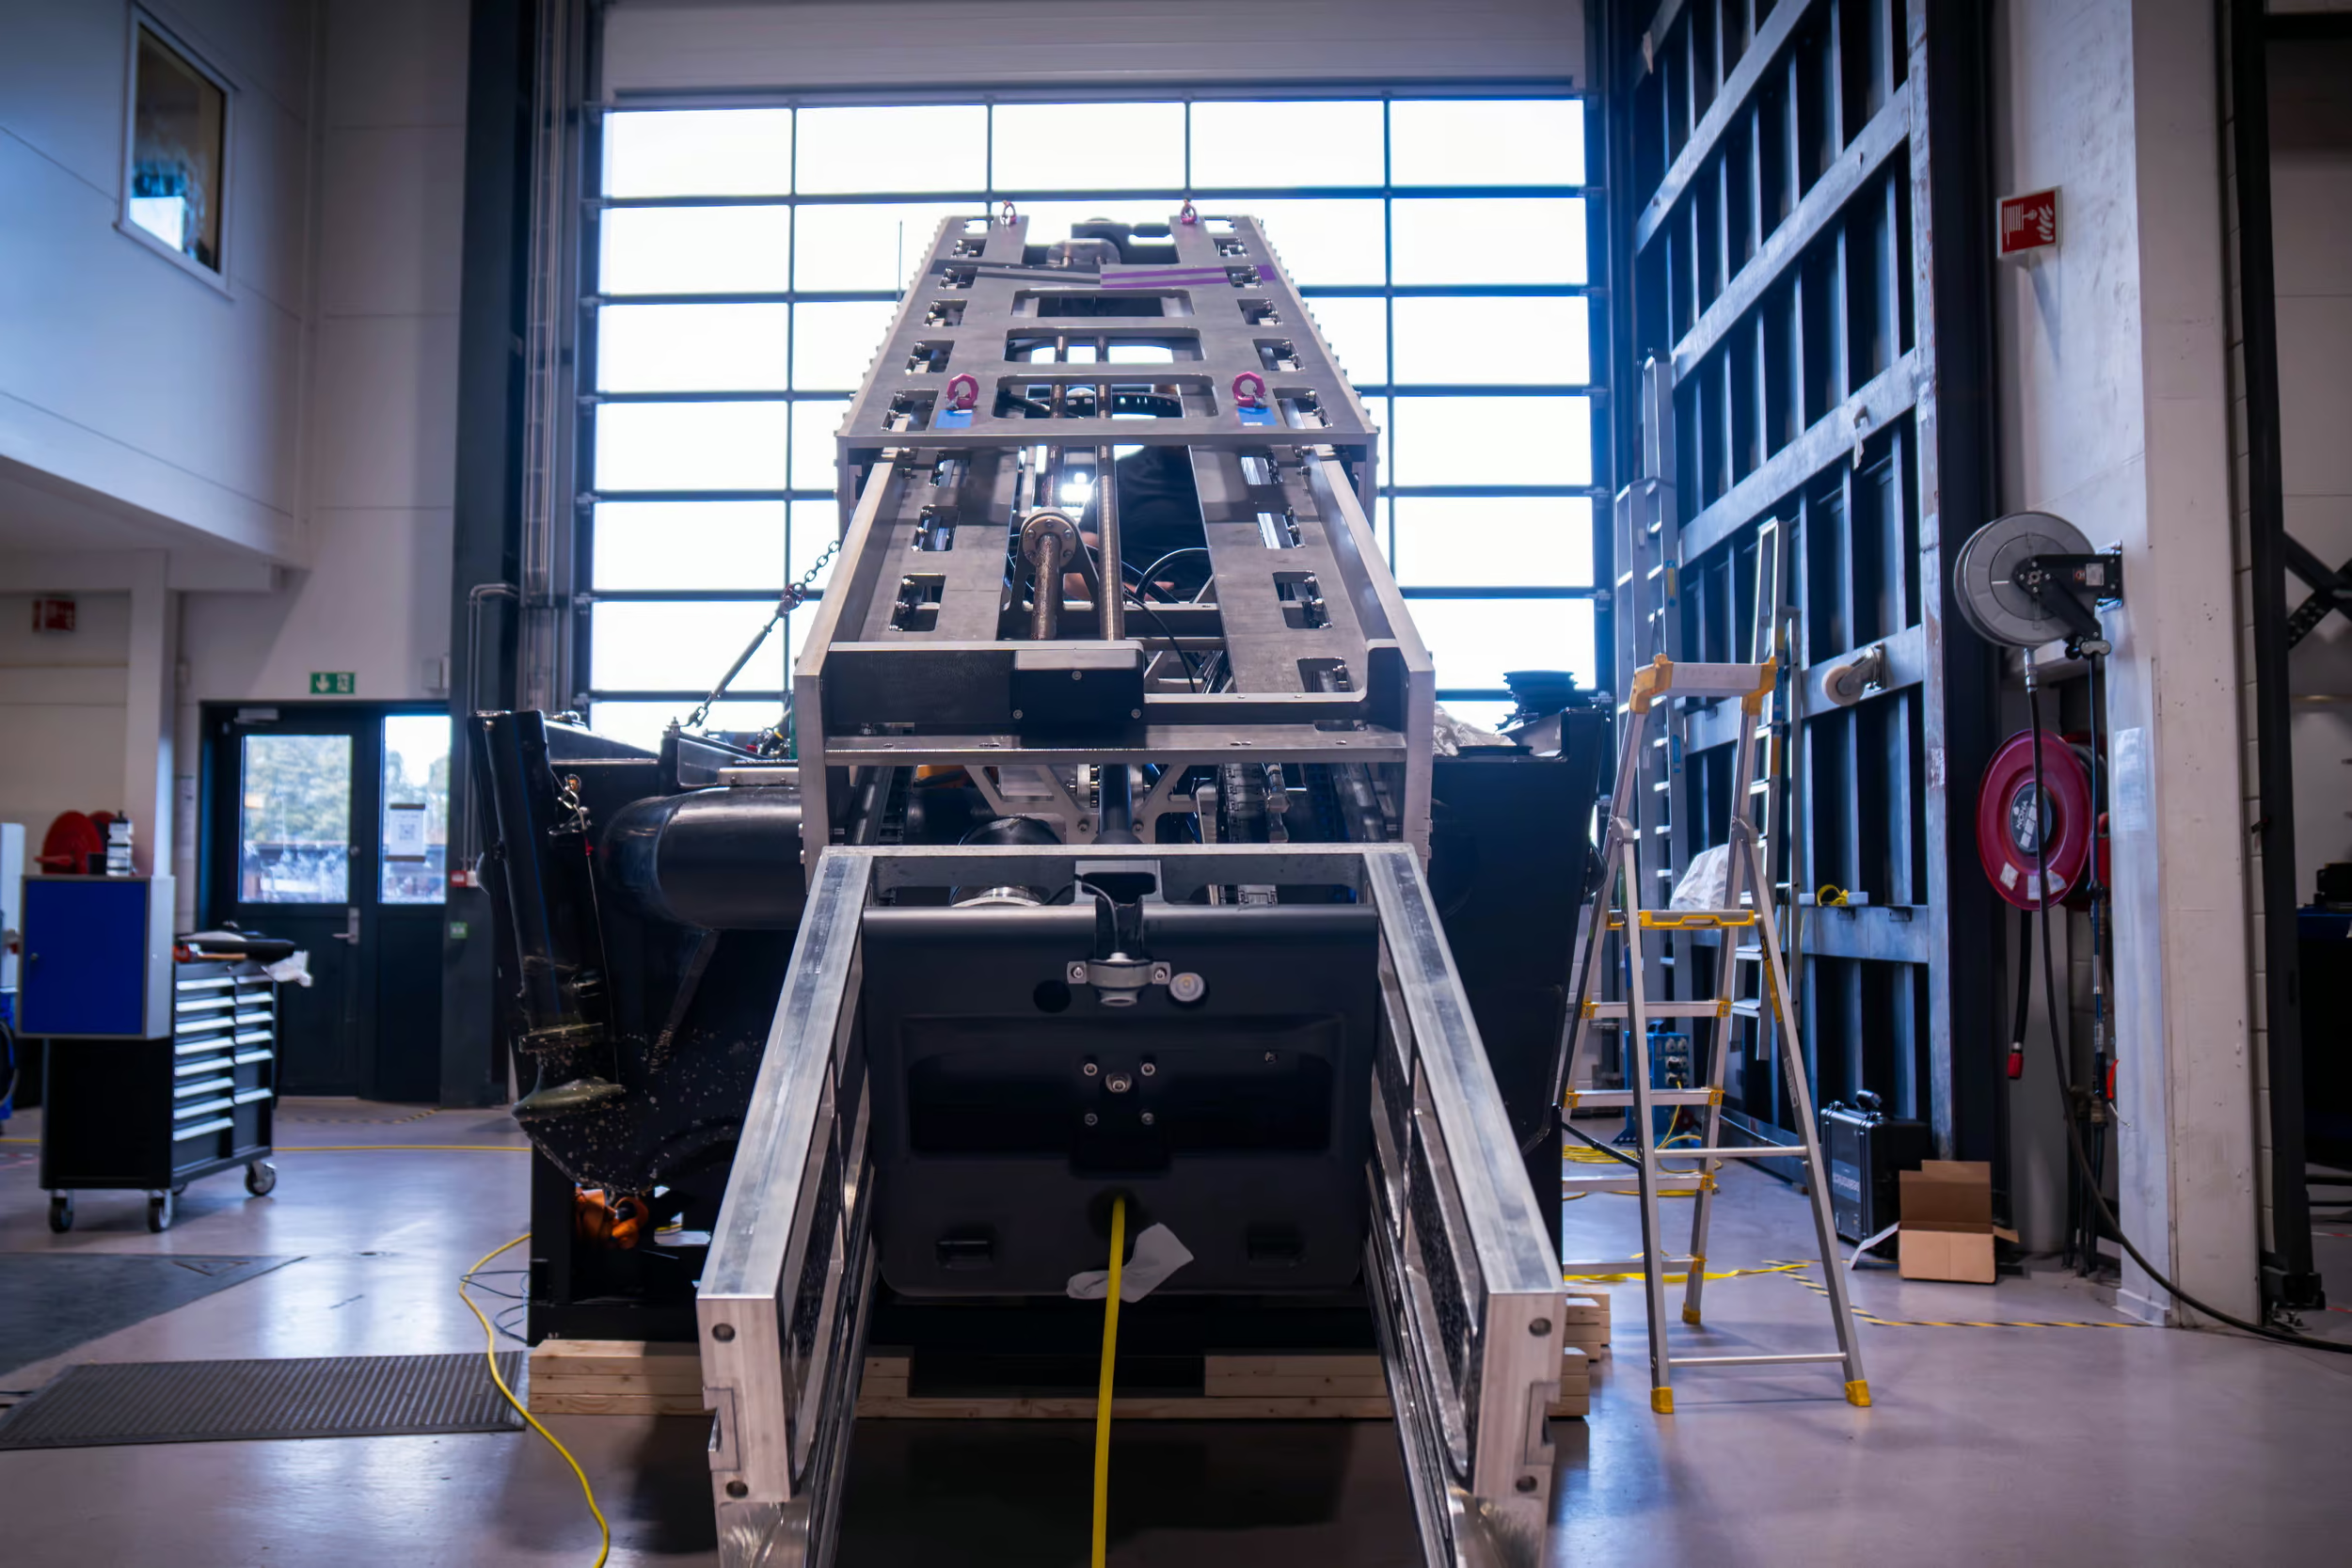
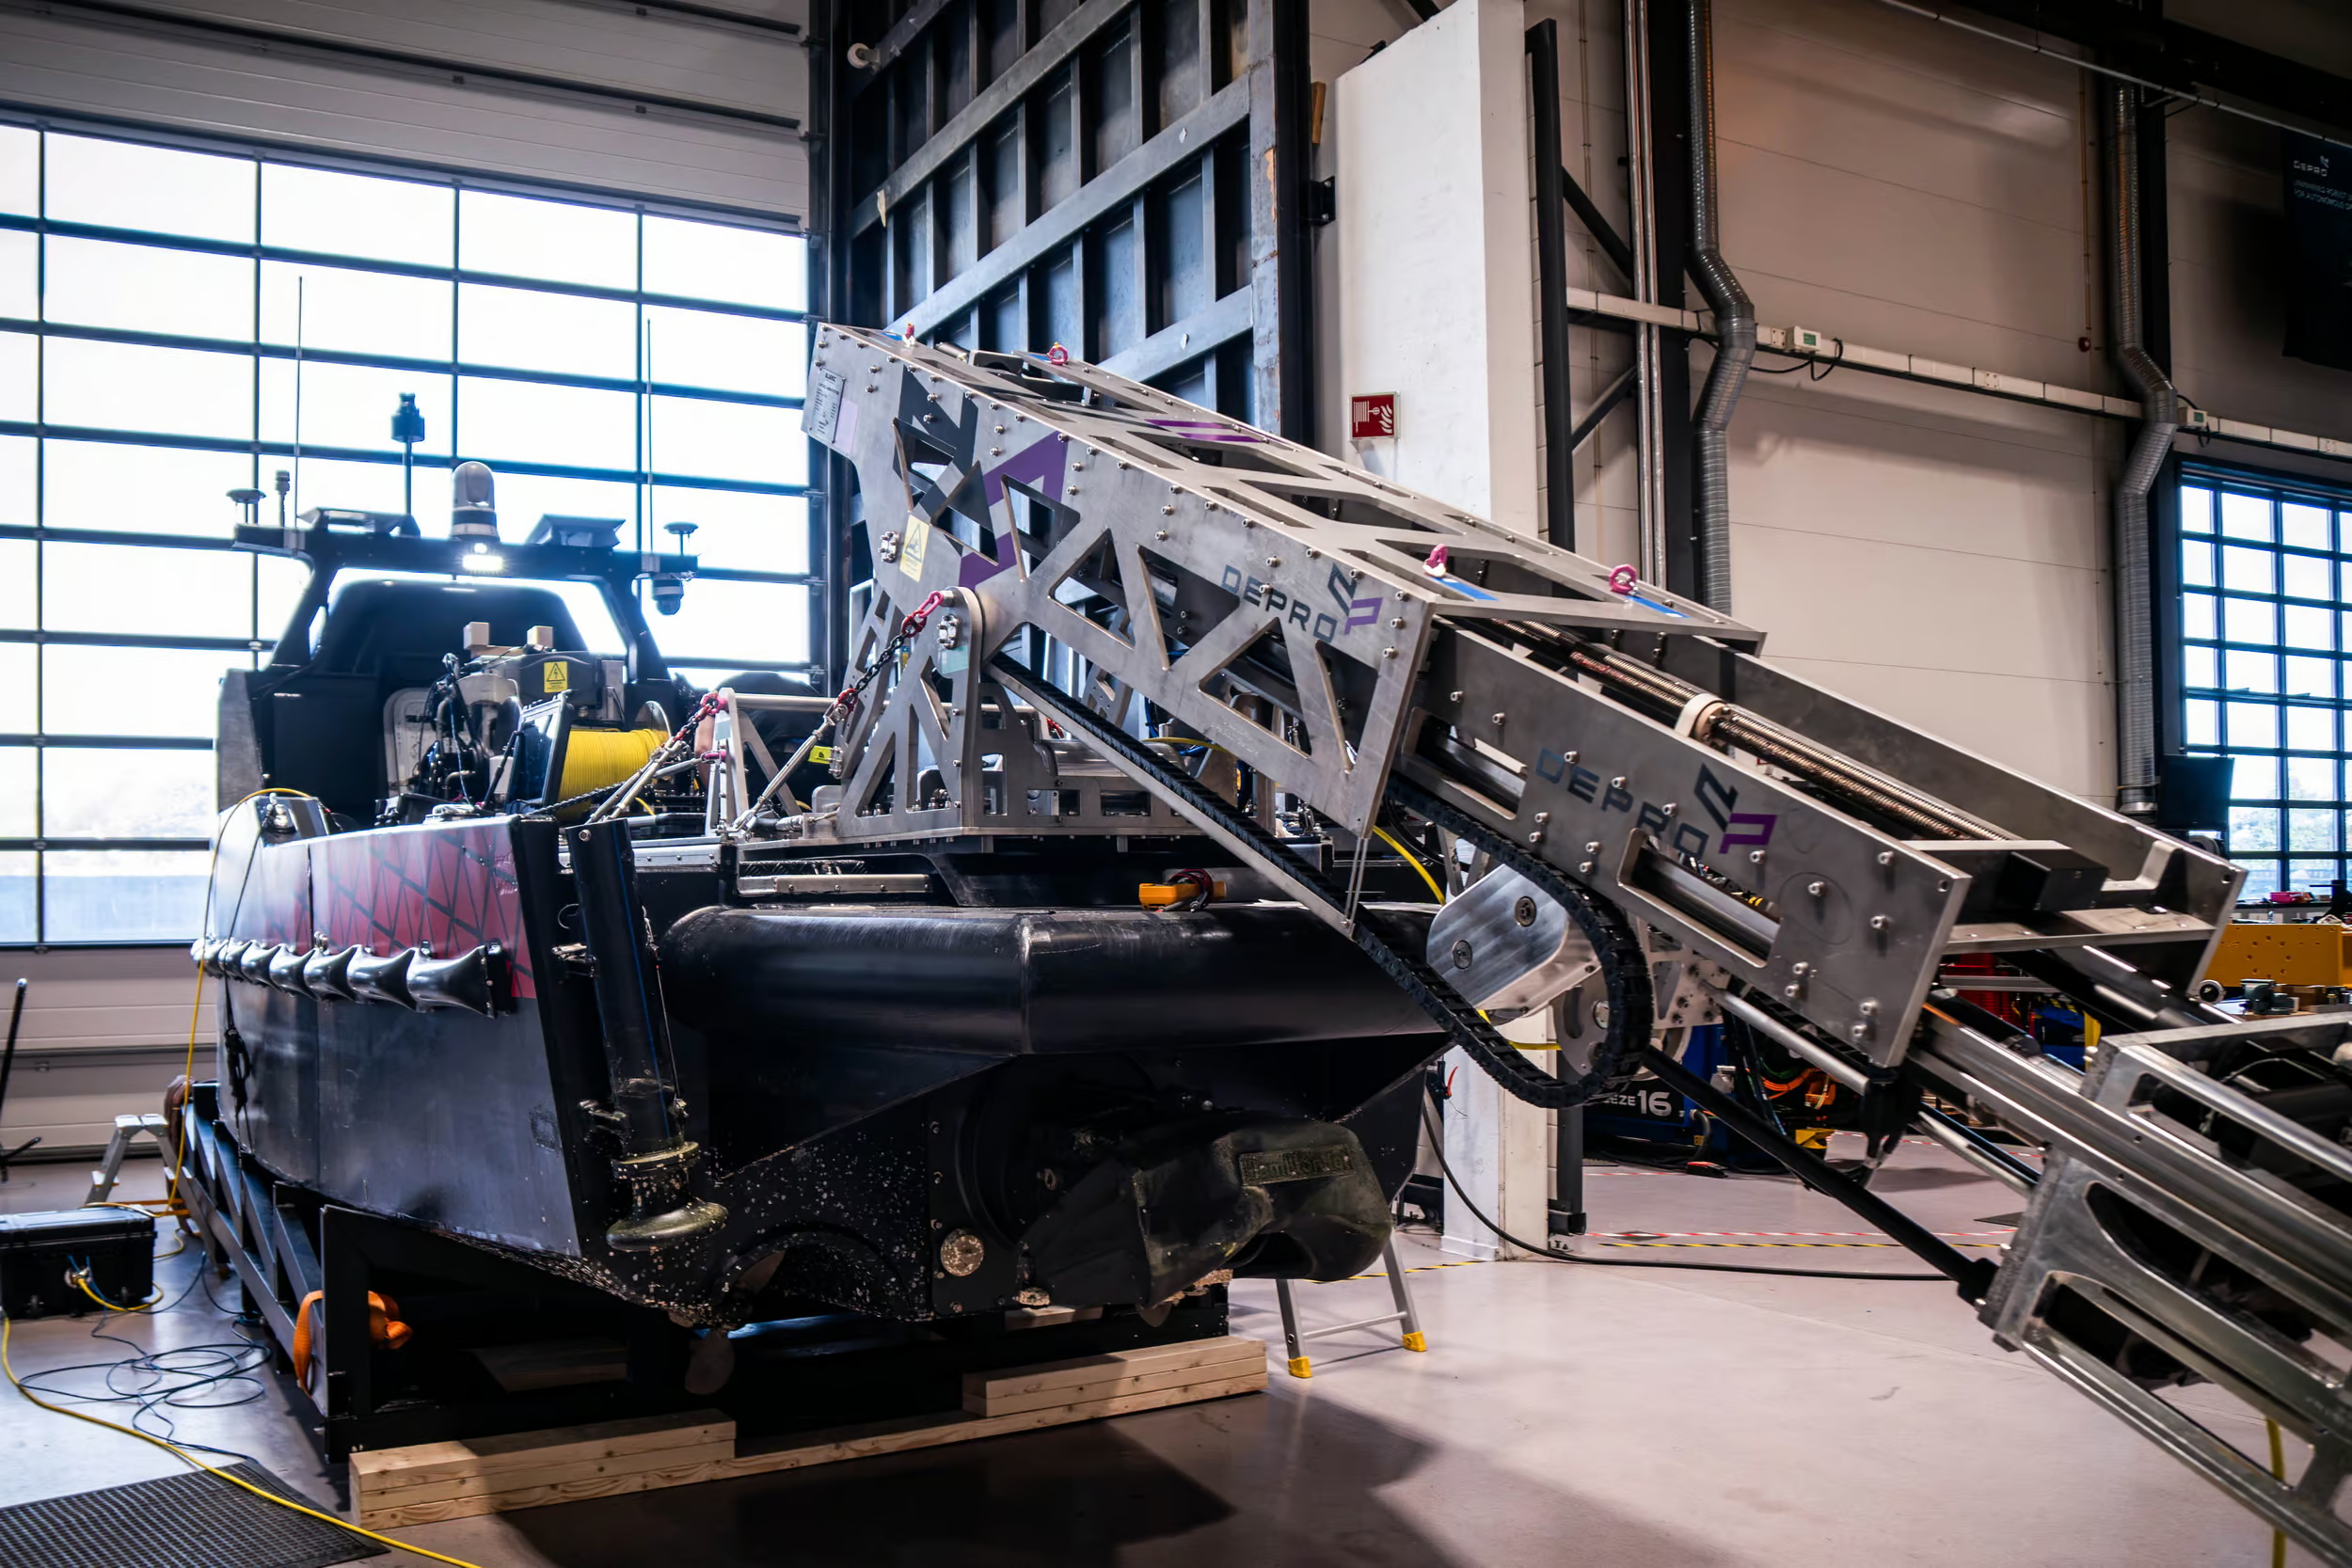
DEPRO’s Surface Launch System (SLS) is designed to make remotely operated vehicle (ROV) operations easier to mobilise from small vessels and uncrewed surface vessels (USVs). Combining launch and recovery, tether handling and remote control, the system provides a practical platform for offshore inspection, survey and subsea monitoring.
Five key capabilities for flexible ROV operations
The system is built around five main capabilities:
1. Rapid mobilisation
Designed for deployment at short notice, the SLS supports flexible mobilisation between vessels and projects.
2. Flexible installation
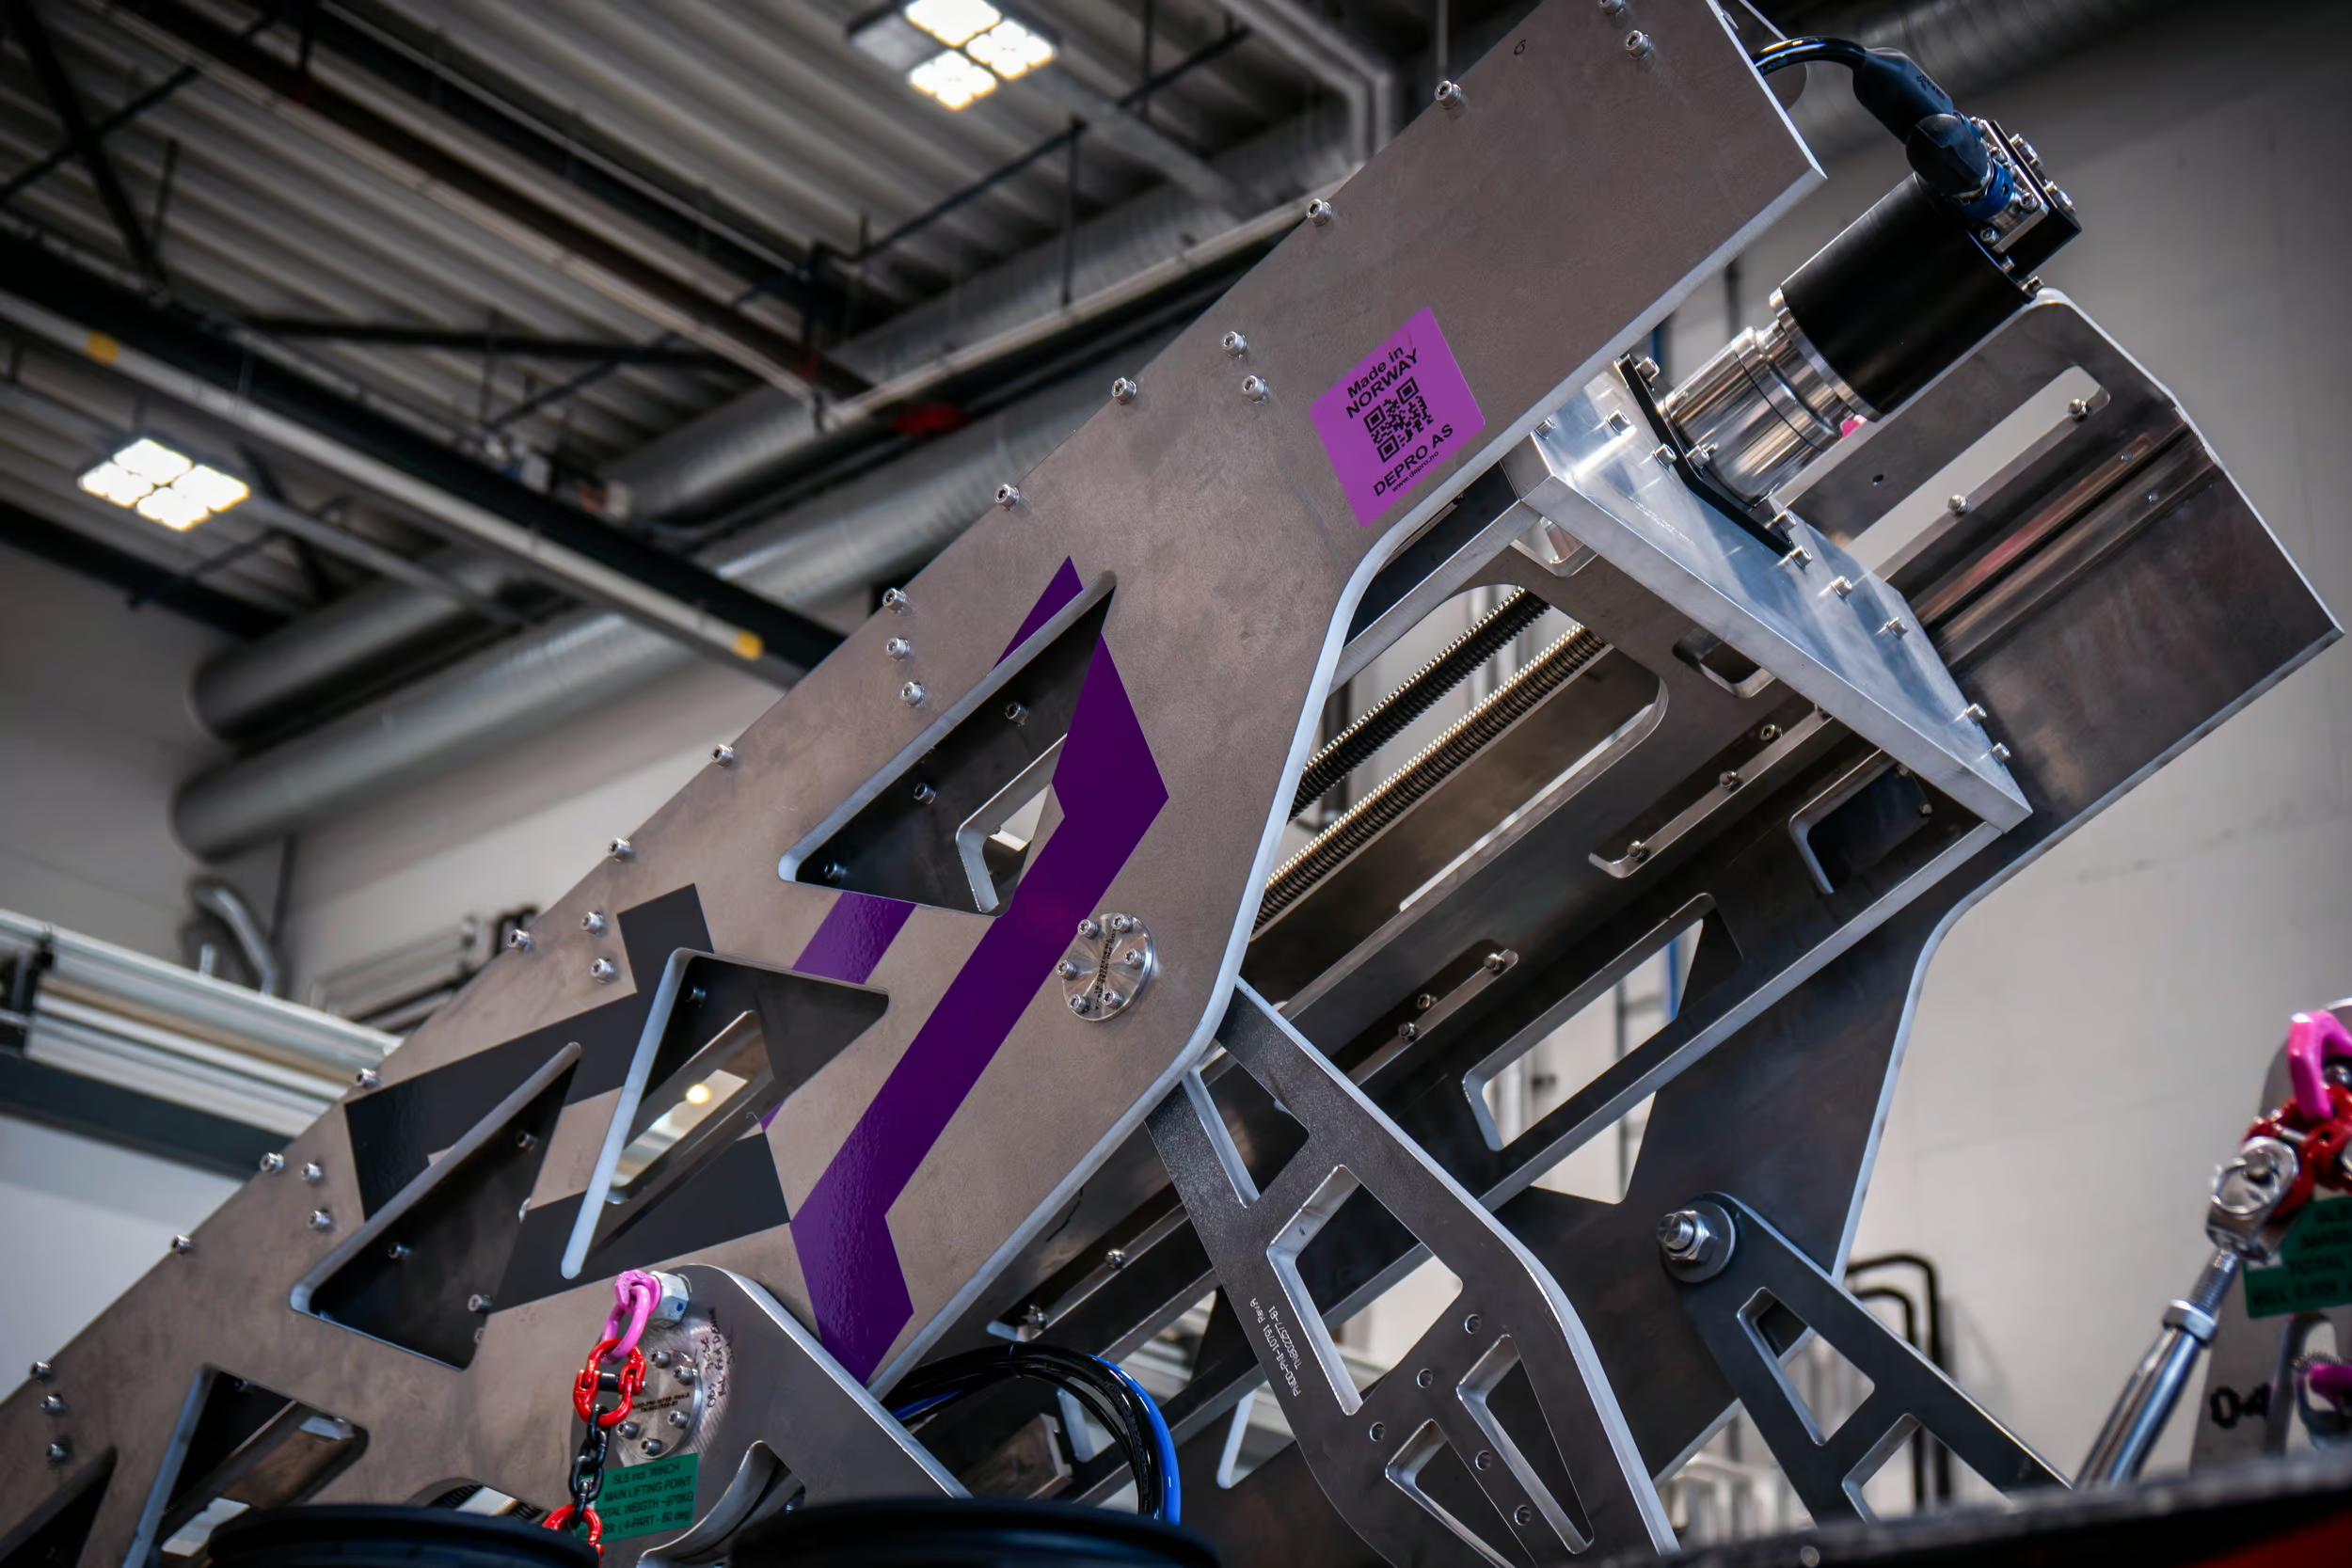
The system can be separated into modules, allowing the launch and recovery unit, winch and tether routing components to be positioned to suit the vessel’s available deck space and layout.
3. Substantial tether capacity
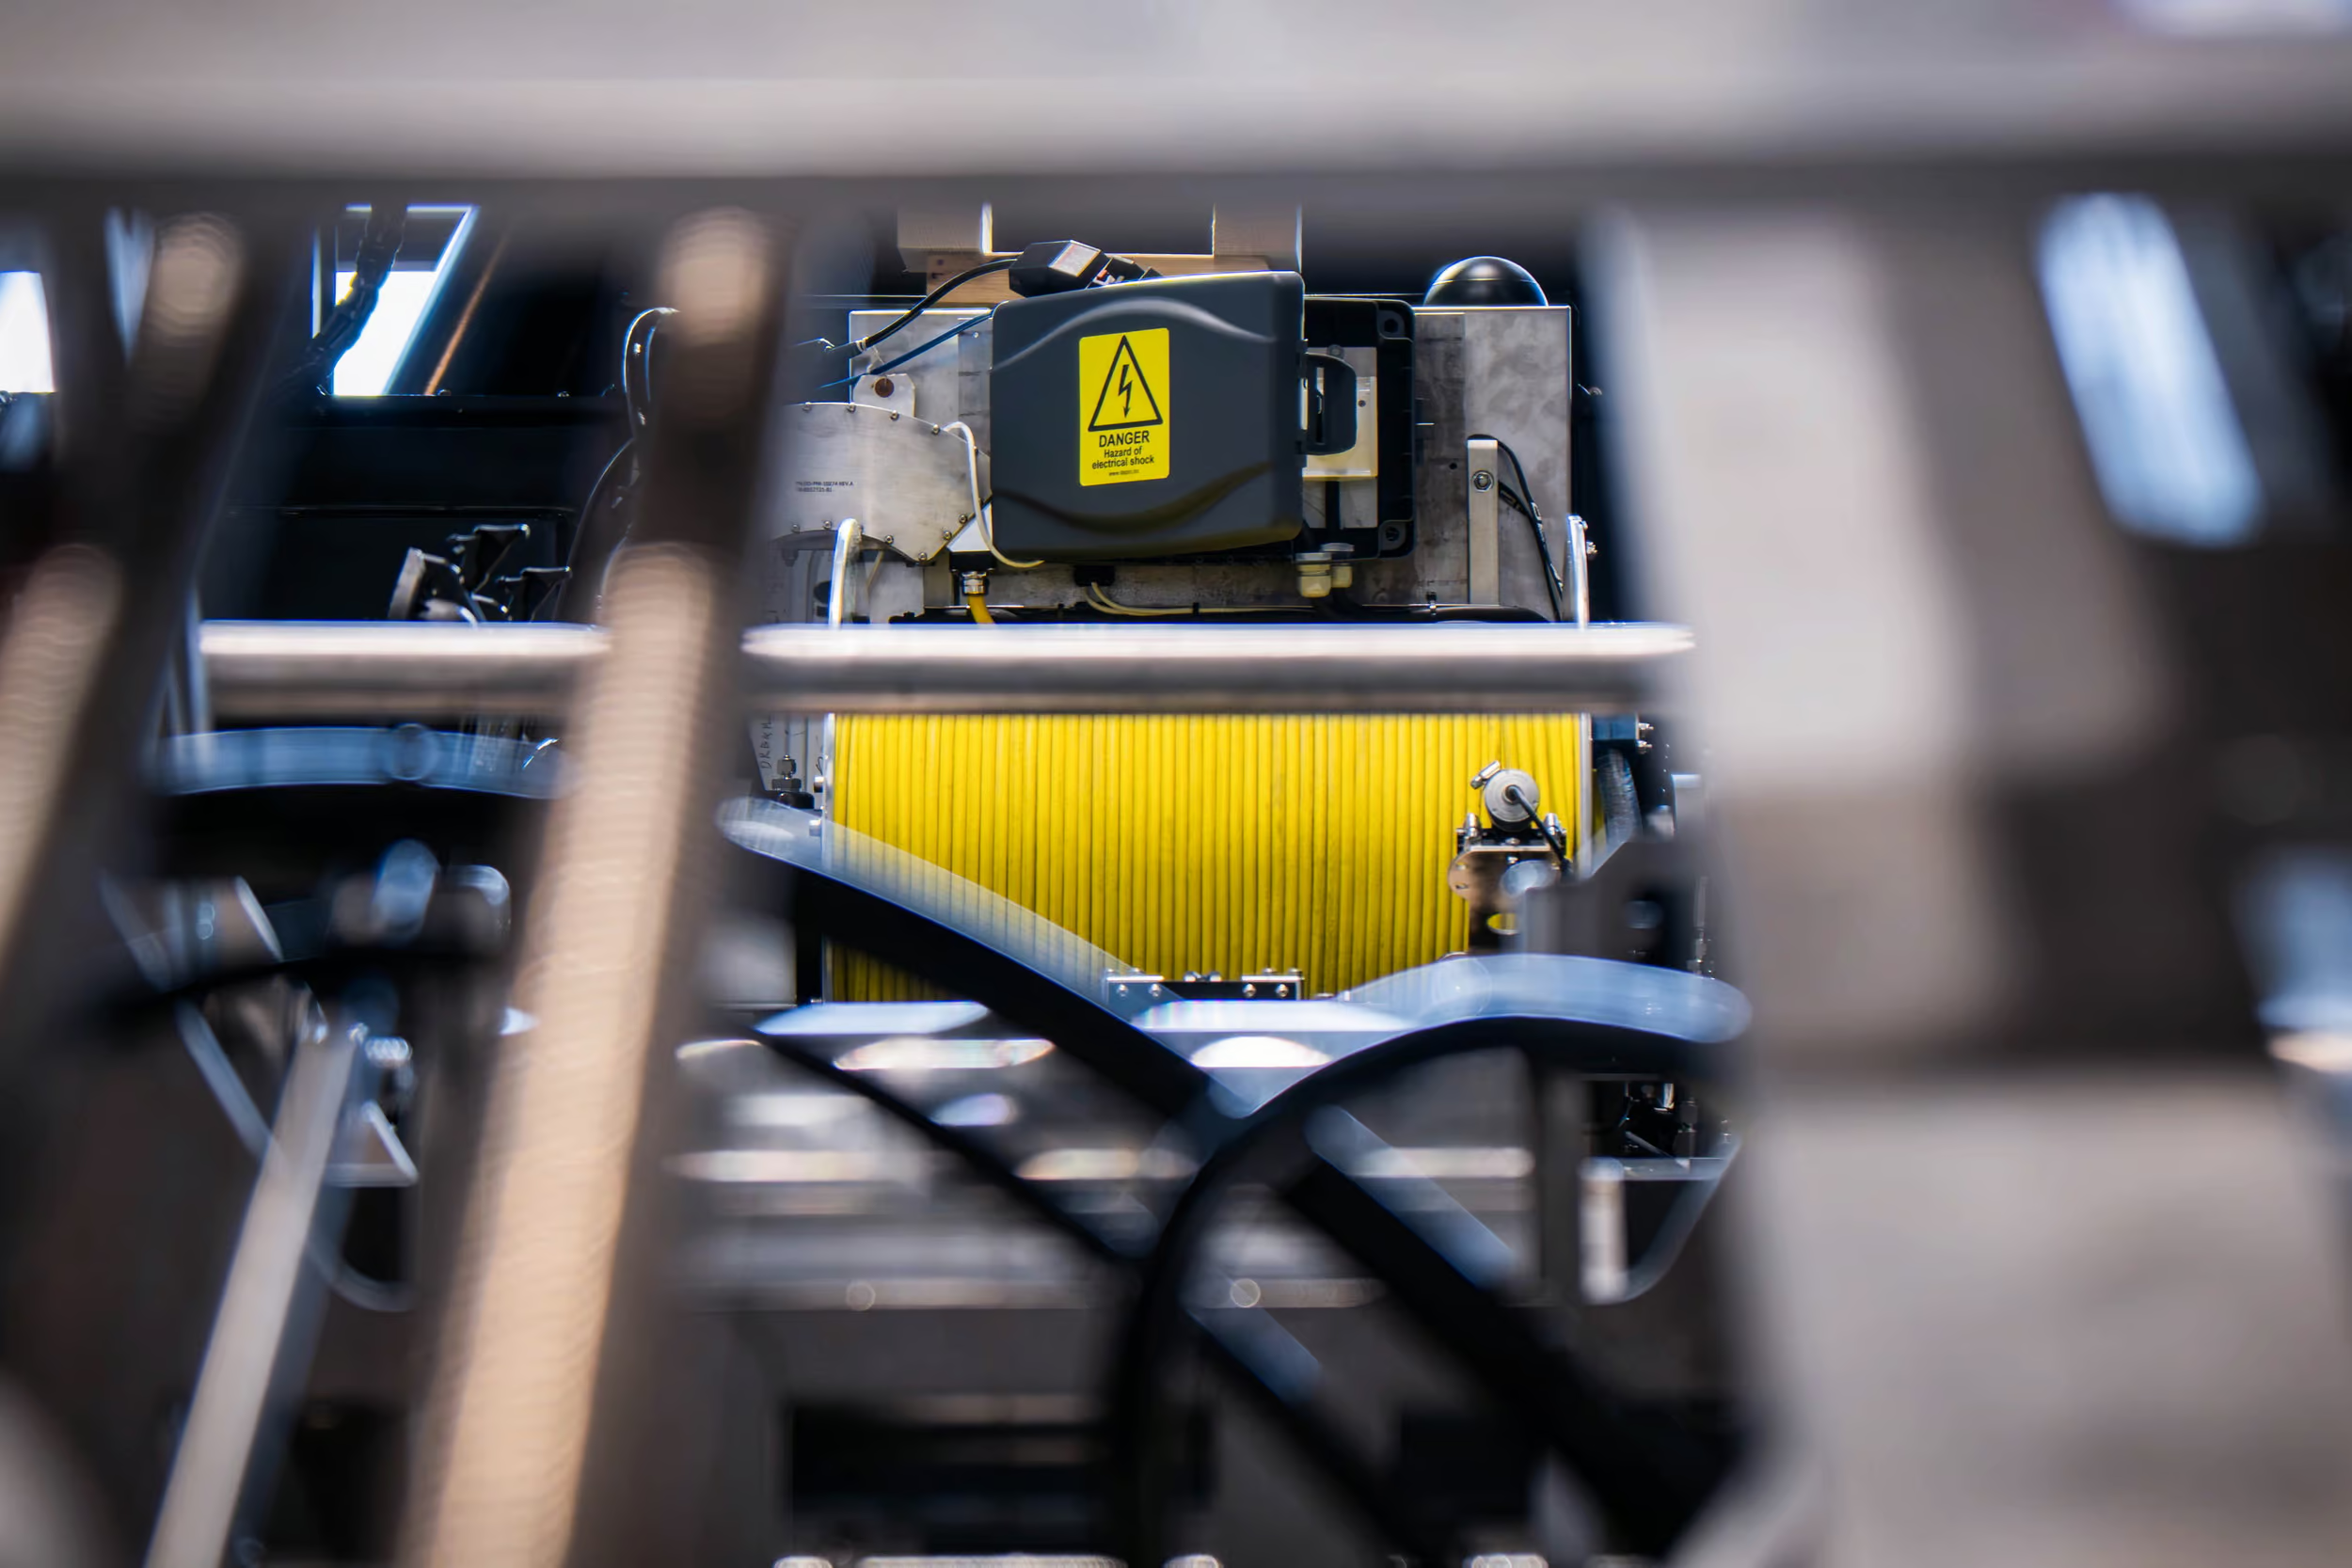
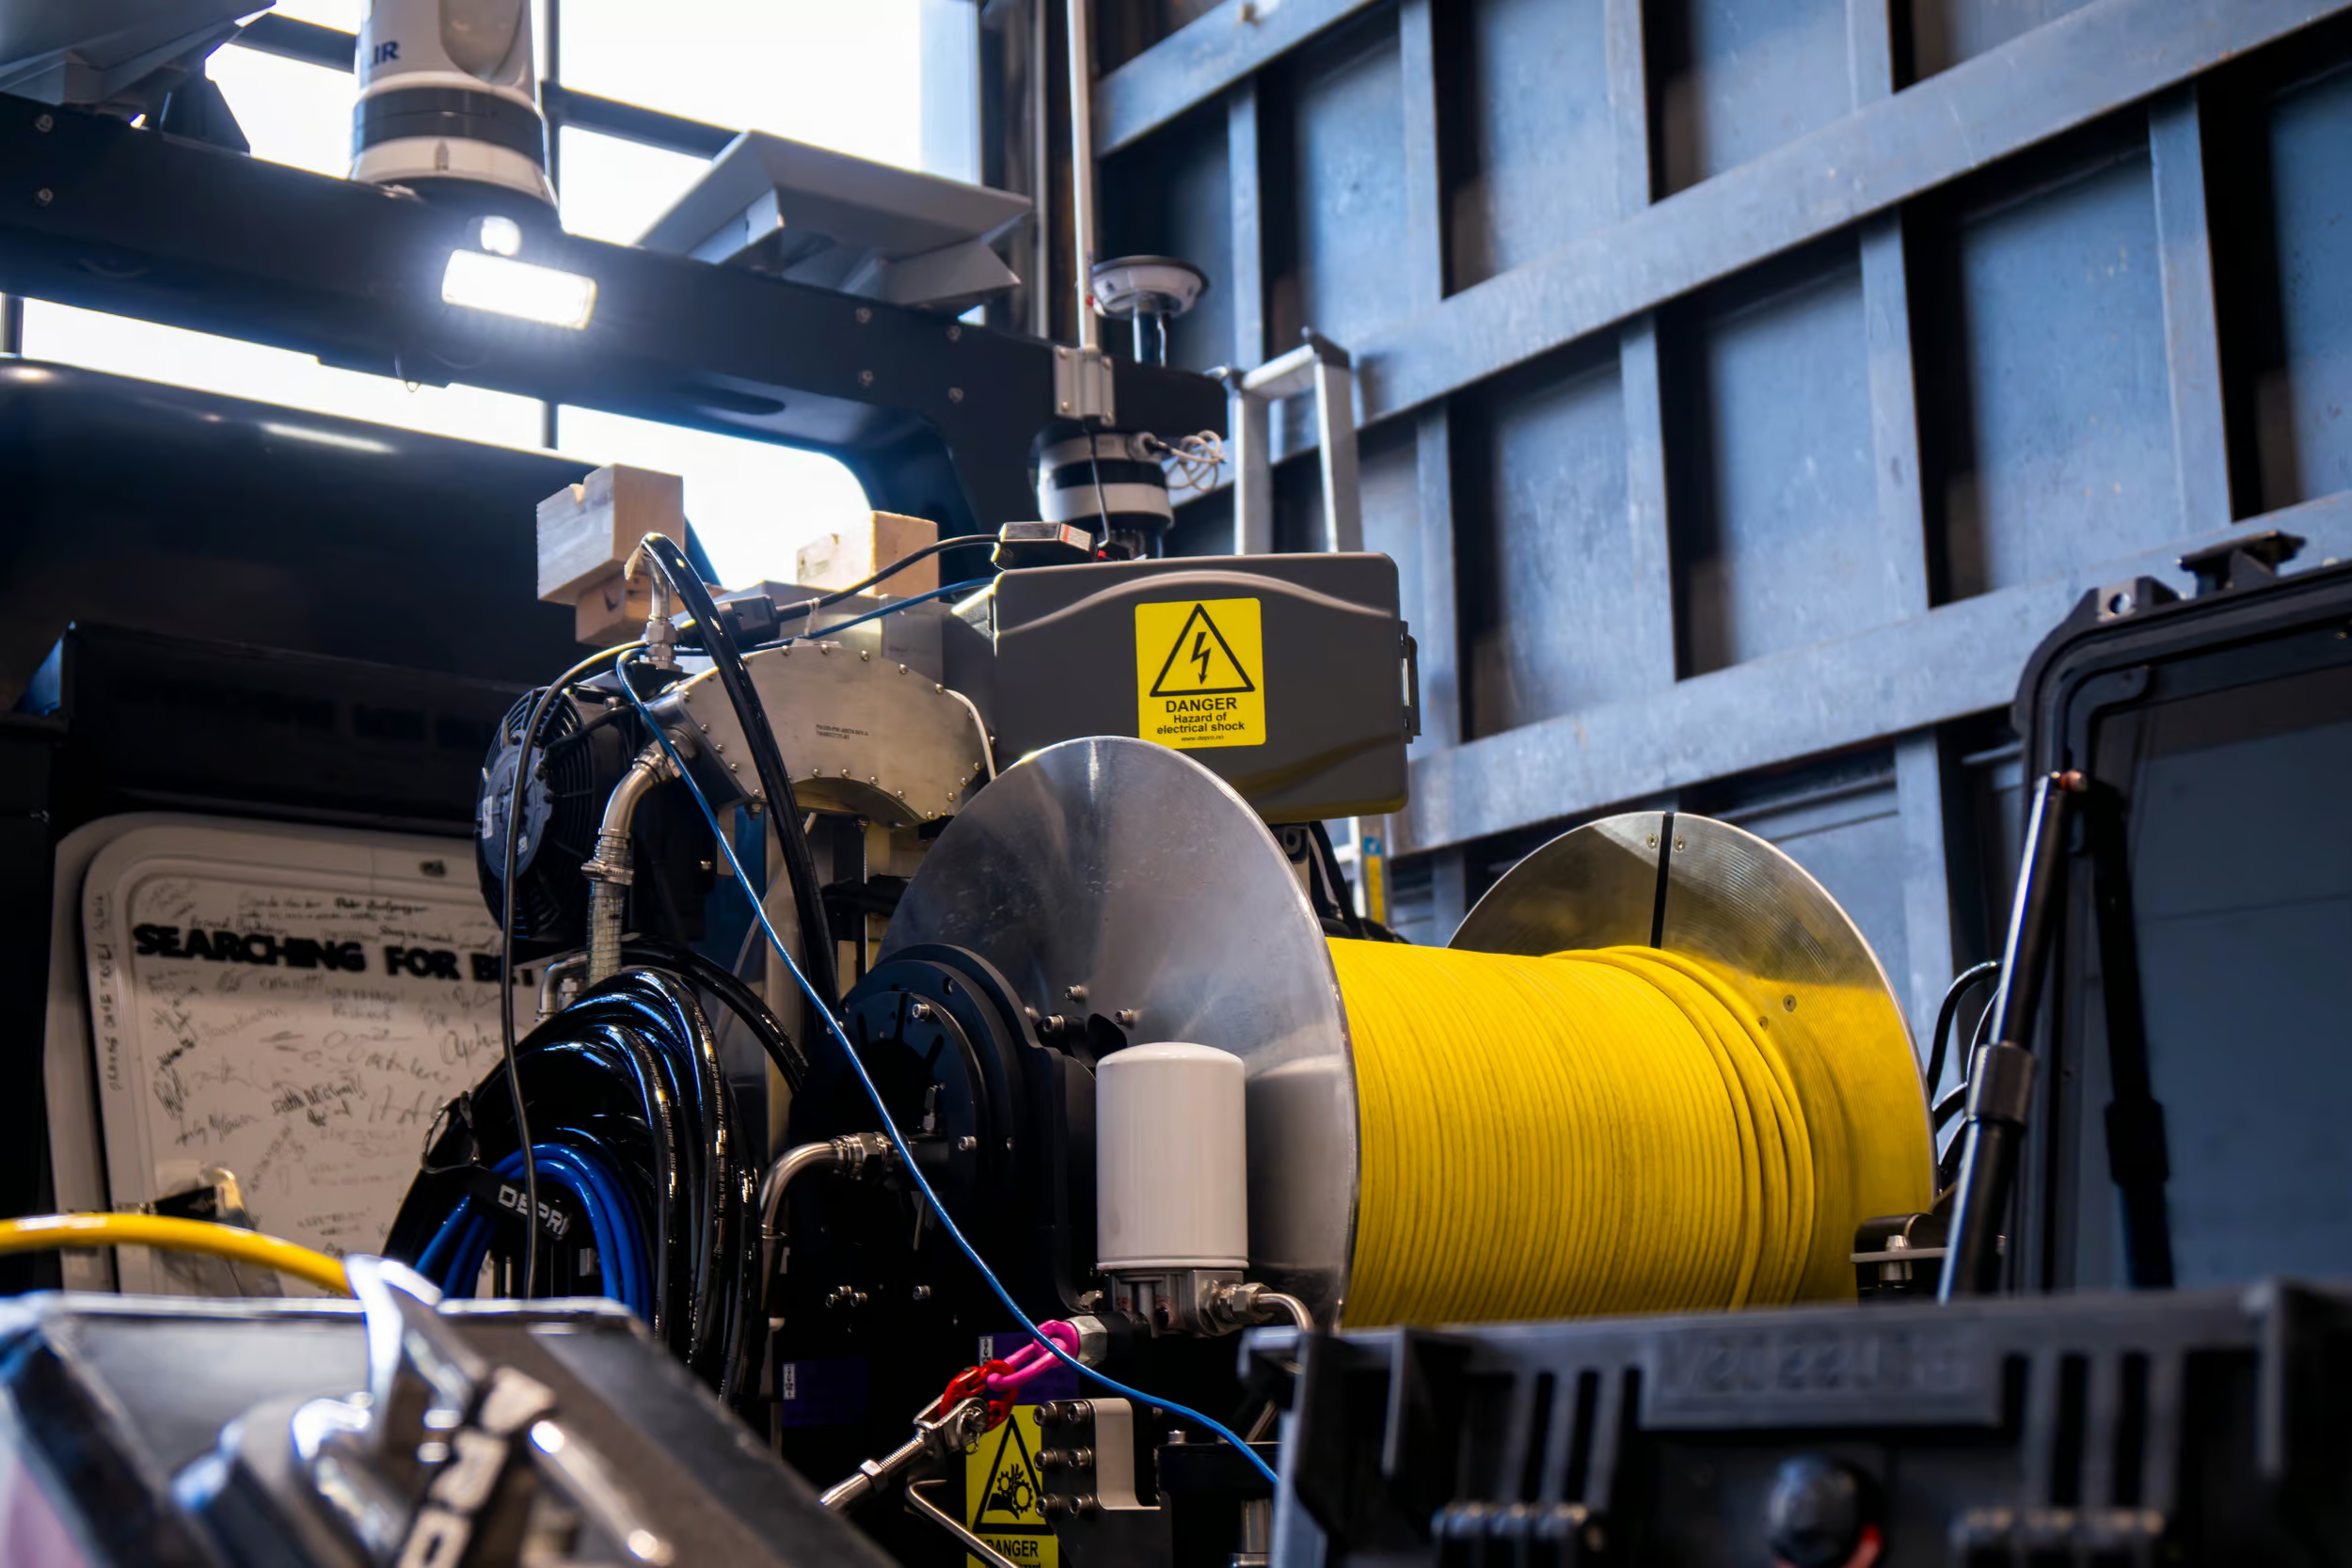
The system accommodates extended tether lengths, providing flexibility when planning the ROV’s working area and operating distance from the vessel.
4. High-bandwidth fibre-optic communication
The connection between the ROV and the surface supports the transfer of large volumes of data, including video, sonar and other sensor data, depending on the ROV configuration. This is particularly relevant for inspection and survey missions involving several data streams.
5. Remote operation and vessel integration
The SLS is remotely controlled and designed for straightforward integration with the vessel’s control and communications architecture, supporting coordinated operation of the vessel and ROV handling system.
Supporting commercial subsea operations
Together, these capabilities support the use of compact vessels and USVs for commercial subsea work, including inspection and monitoring of offshore energy infrastructure.
As part of DEPRO’s BLUEROC™ product family, the SLS features a modular arrangement that allows the installation to be adapted to the vessel, while the fibre-optic connection supports increasingly data-intensive ROV missions.
Preparing for testing at Equinor’s Kårstø test centre
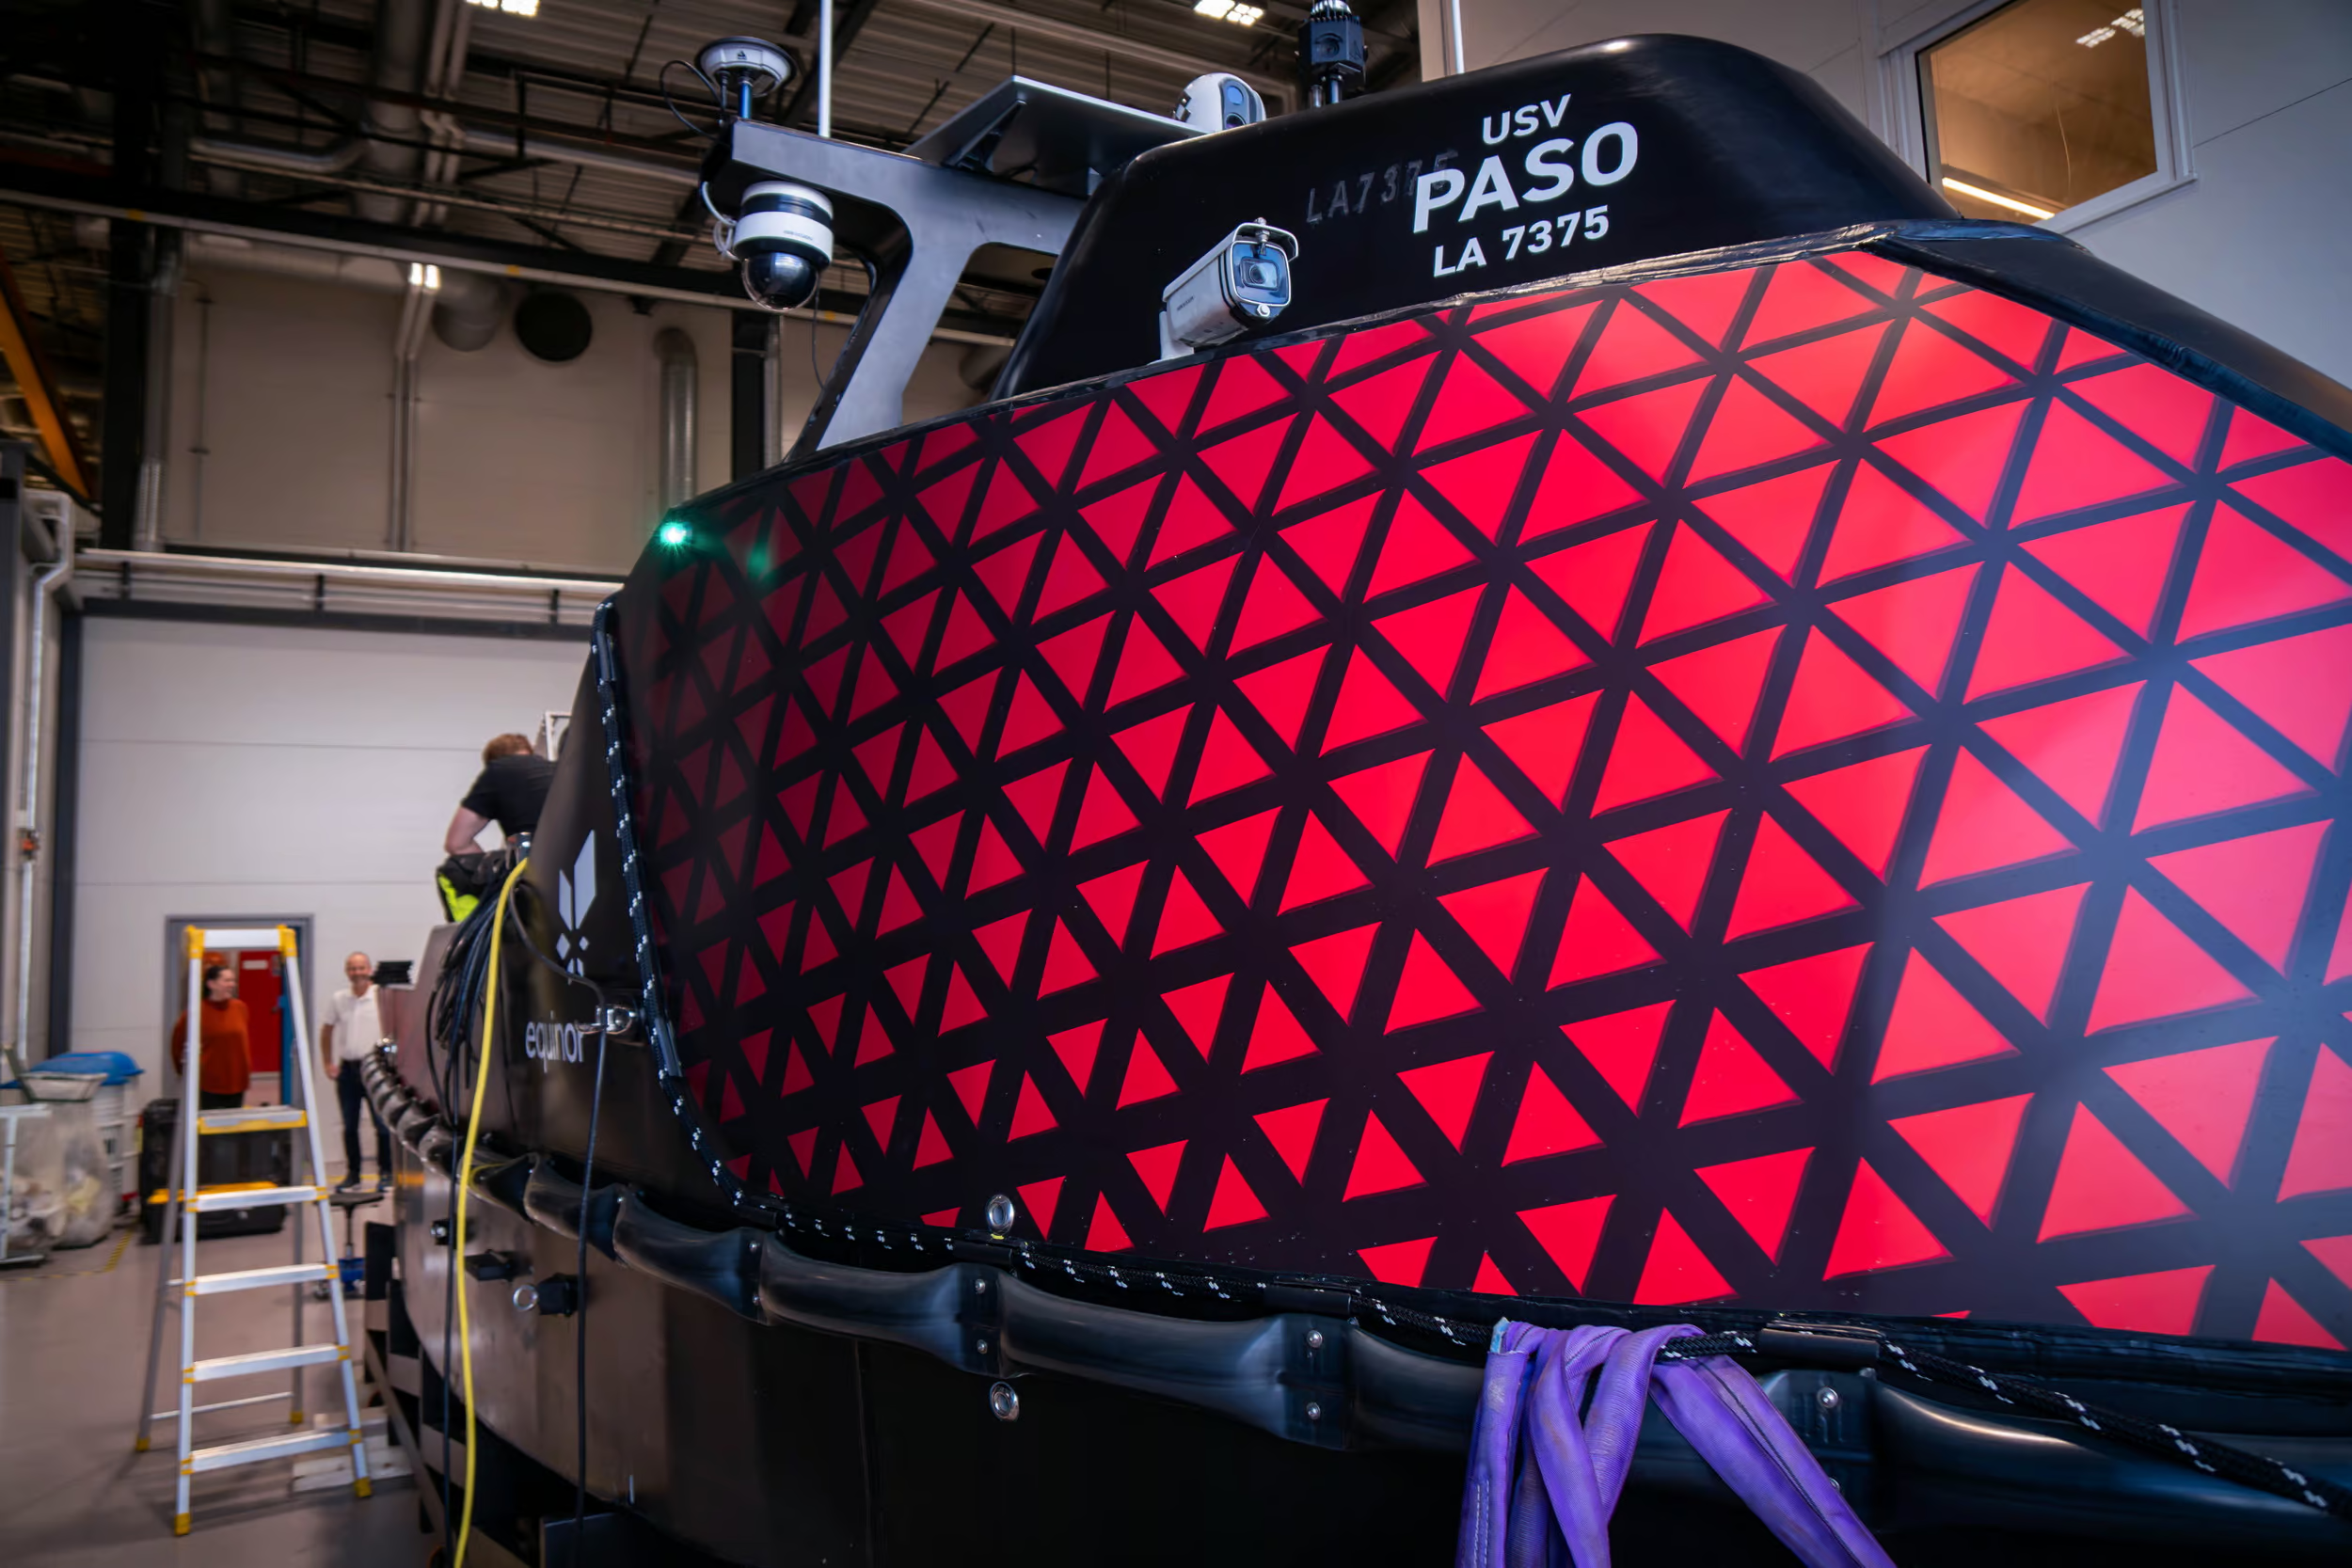
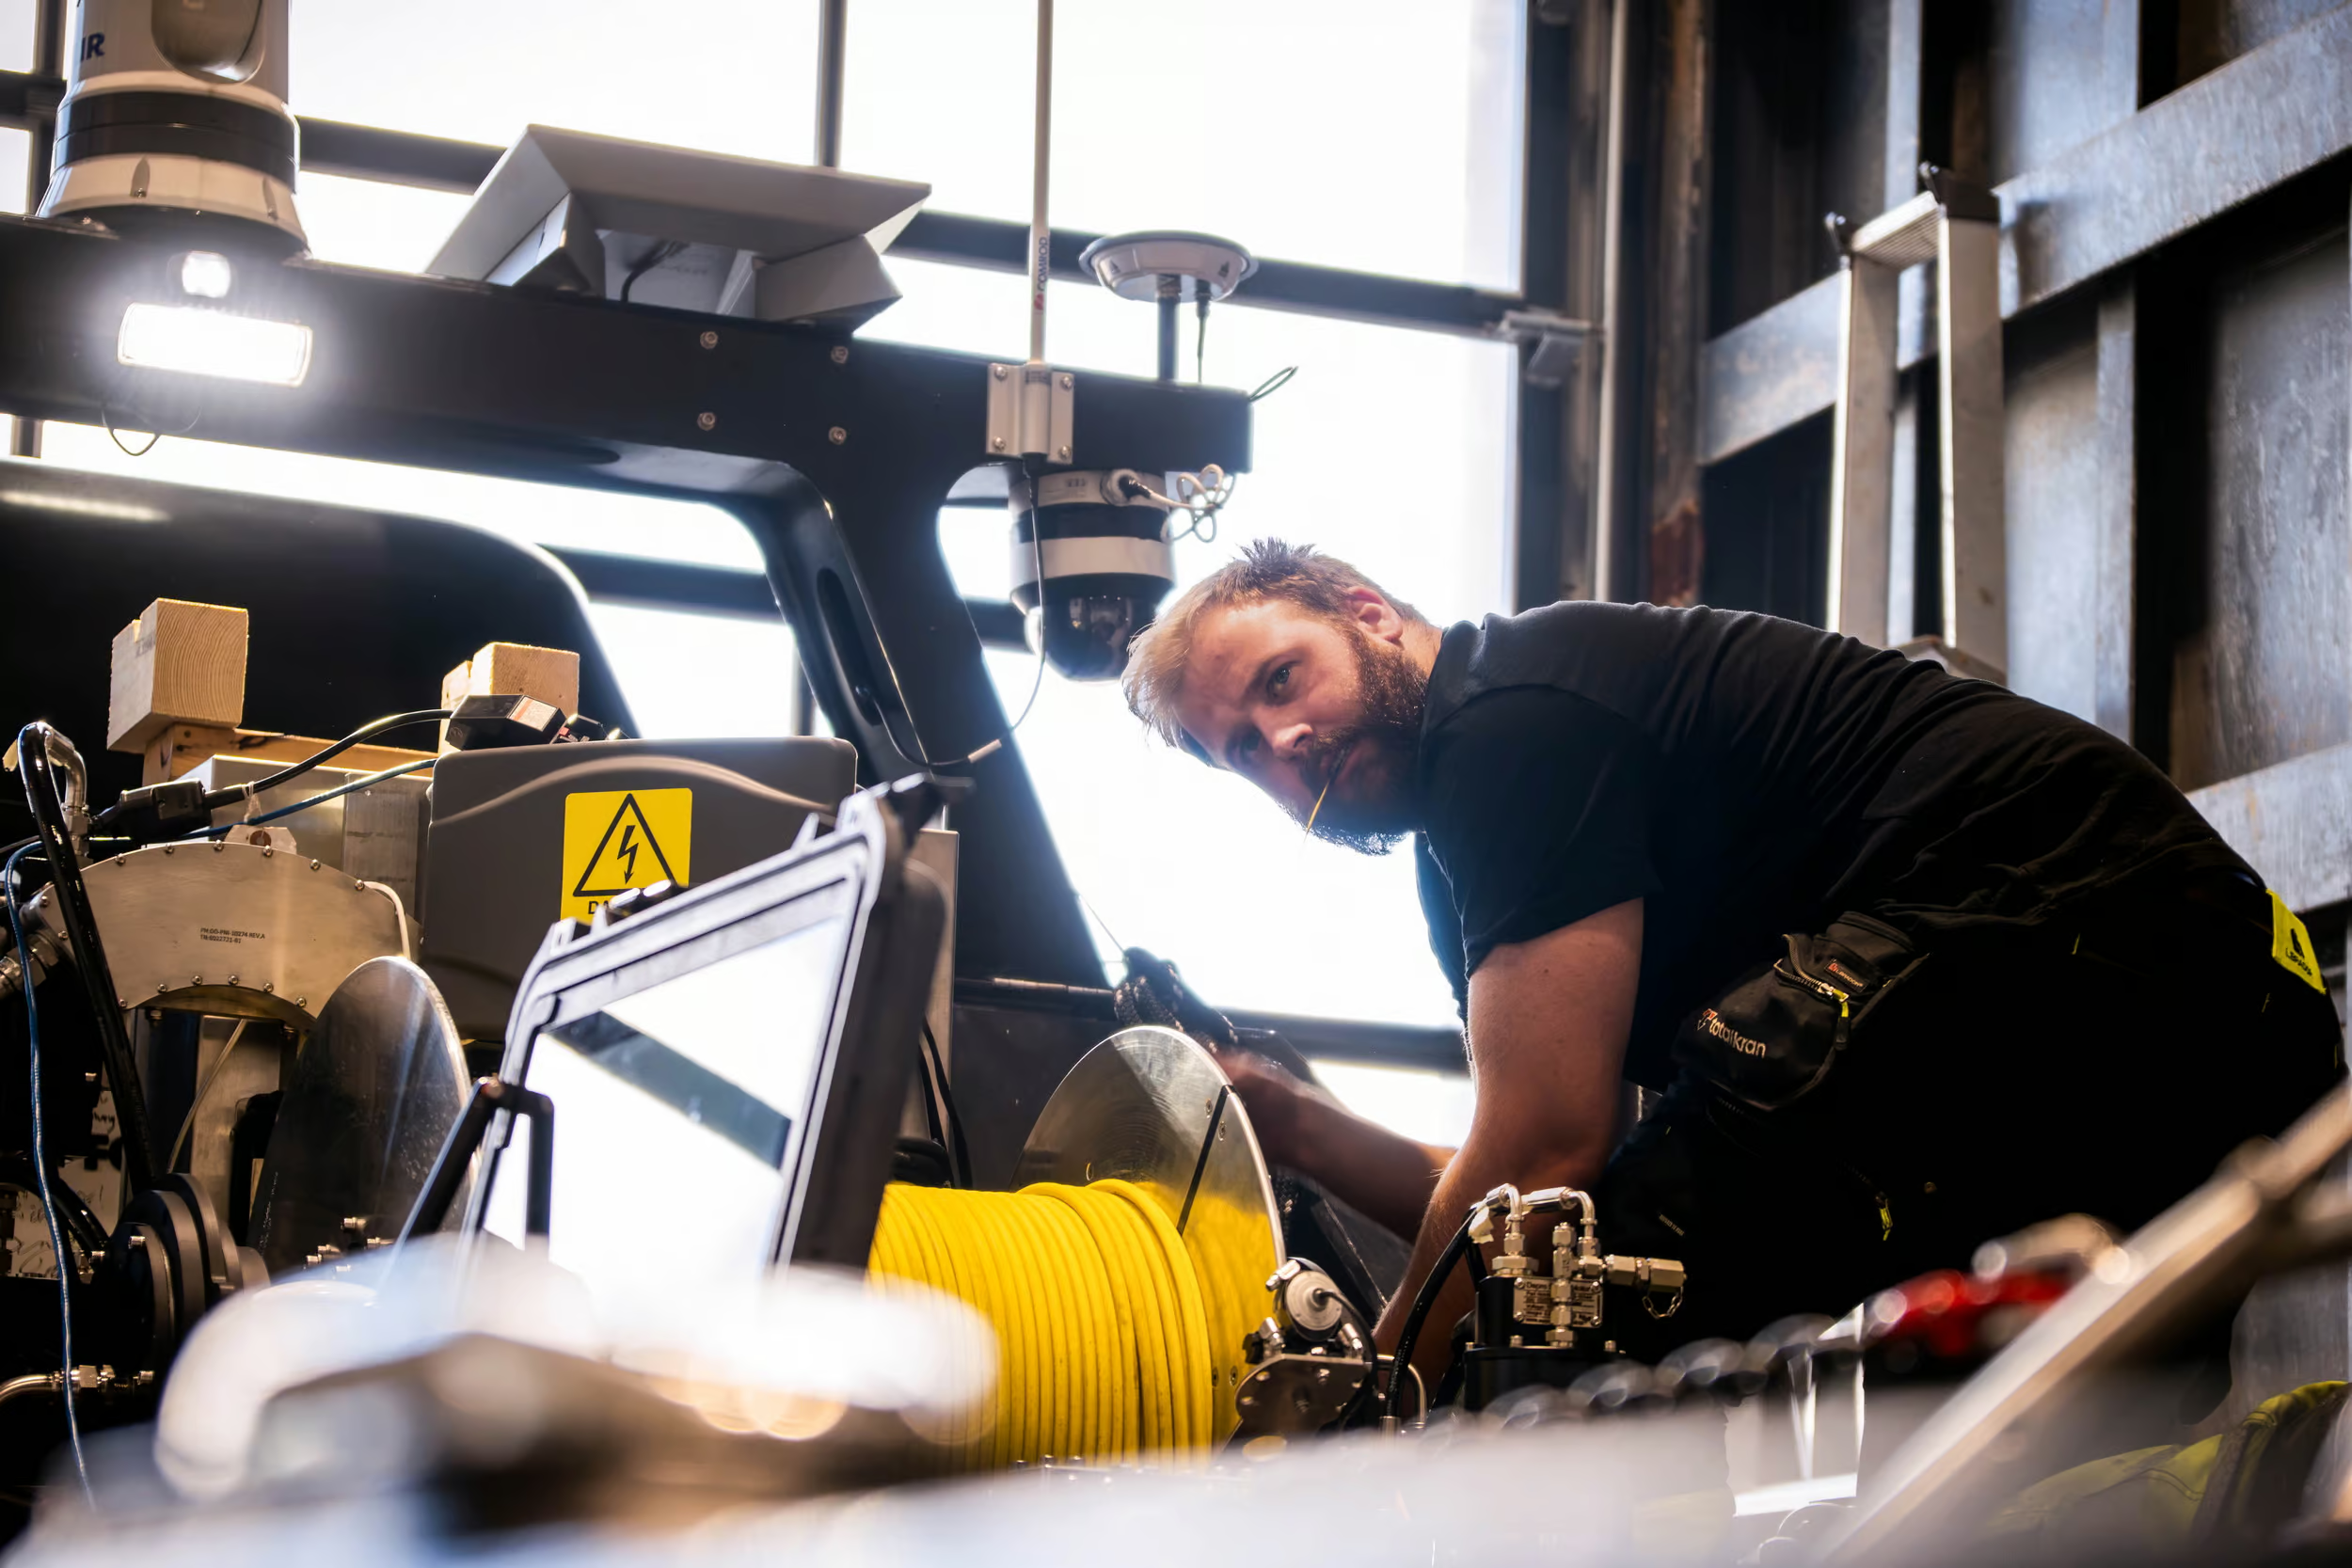
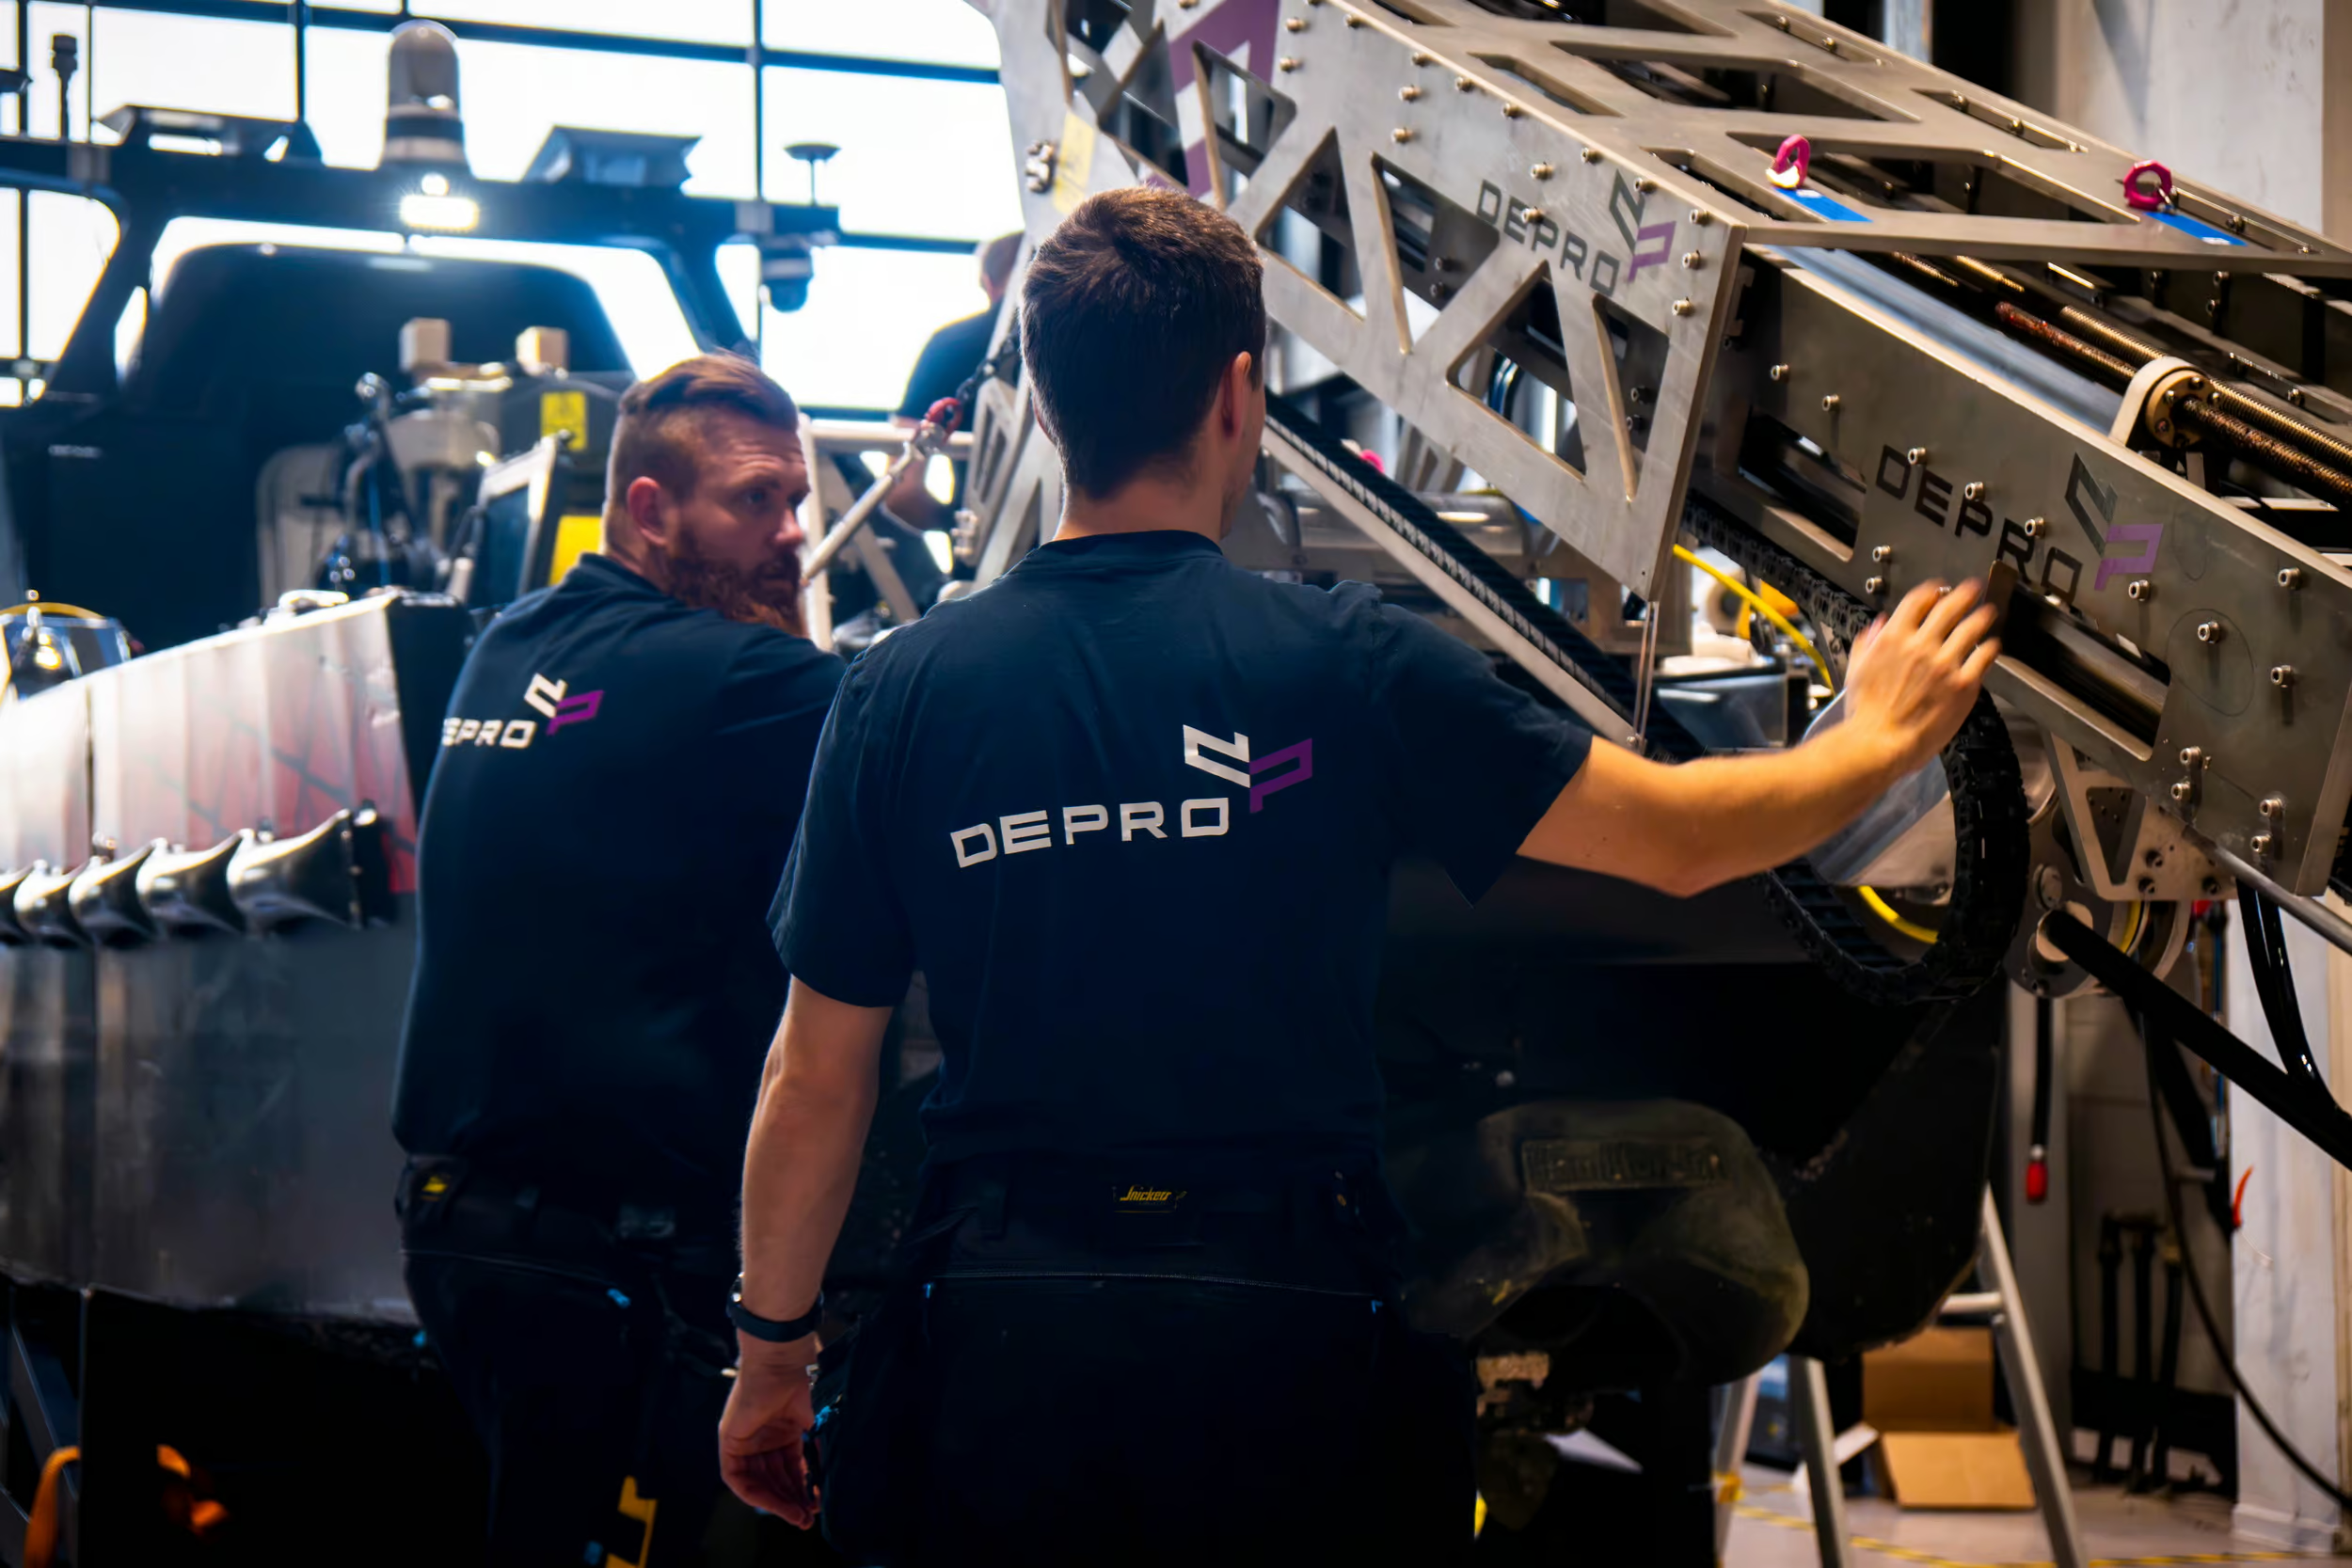
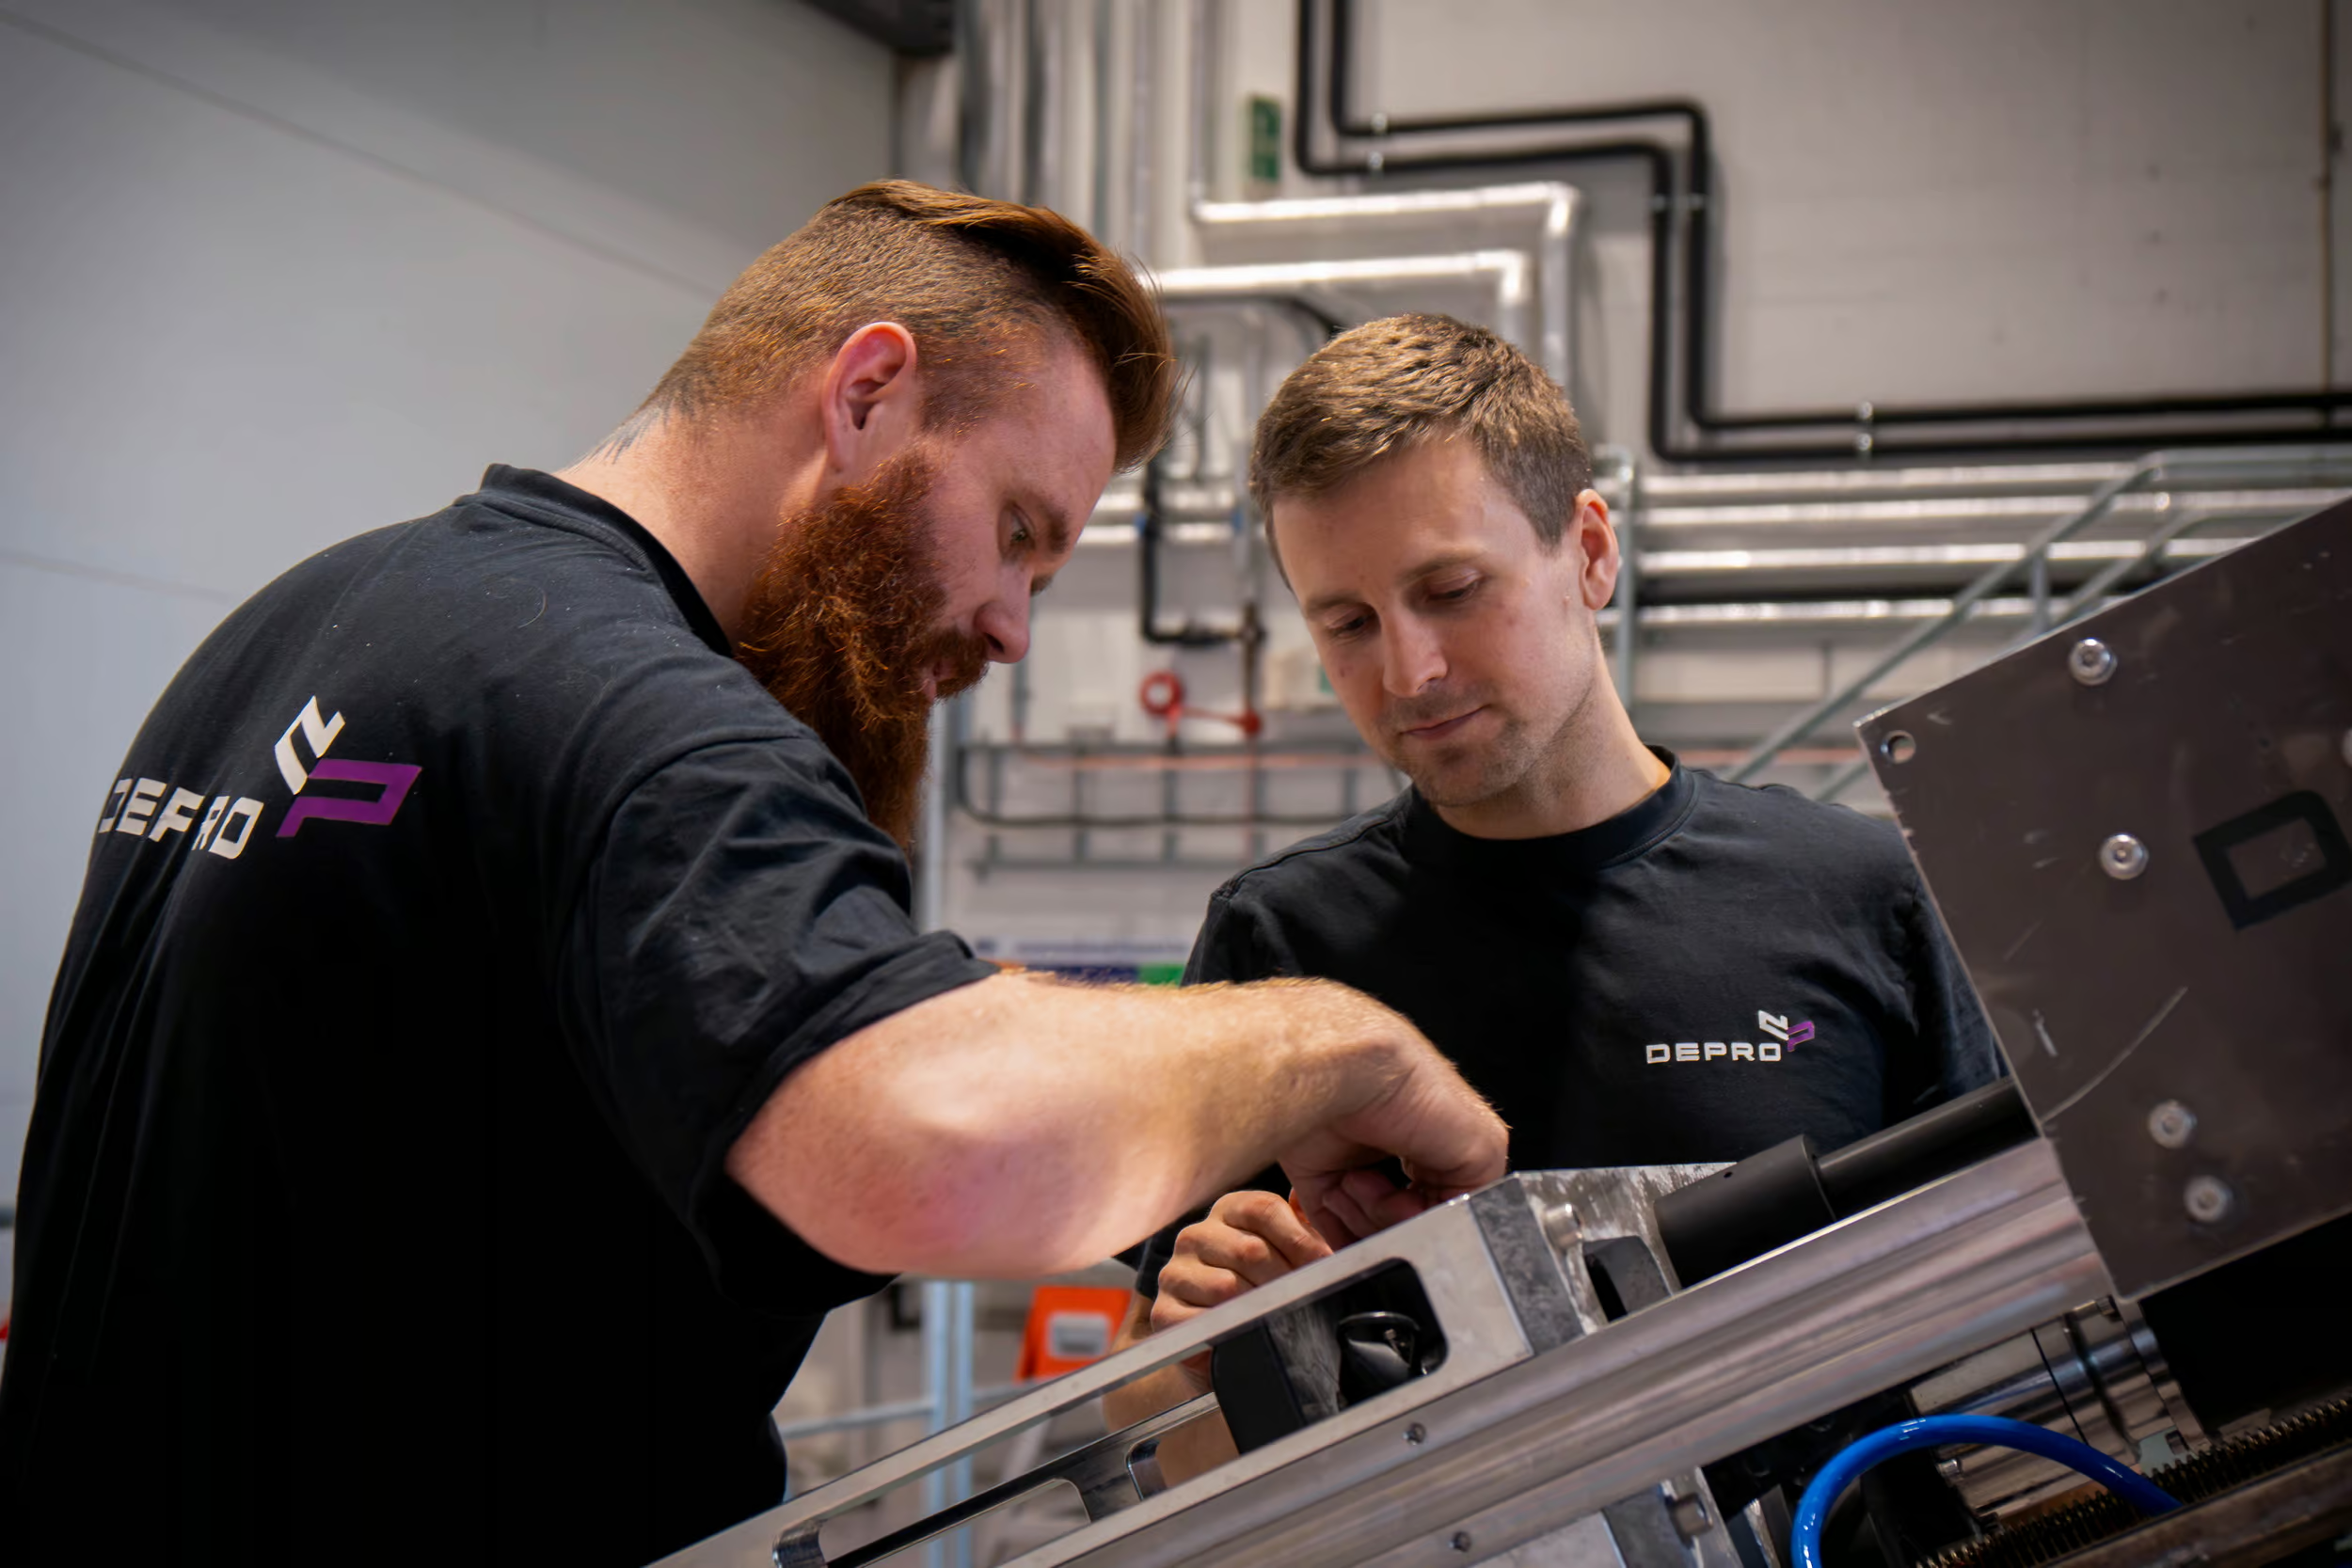
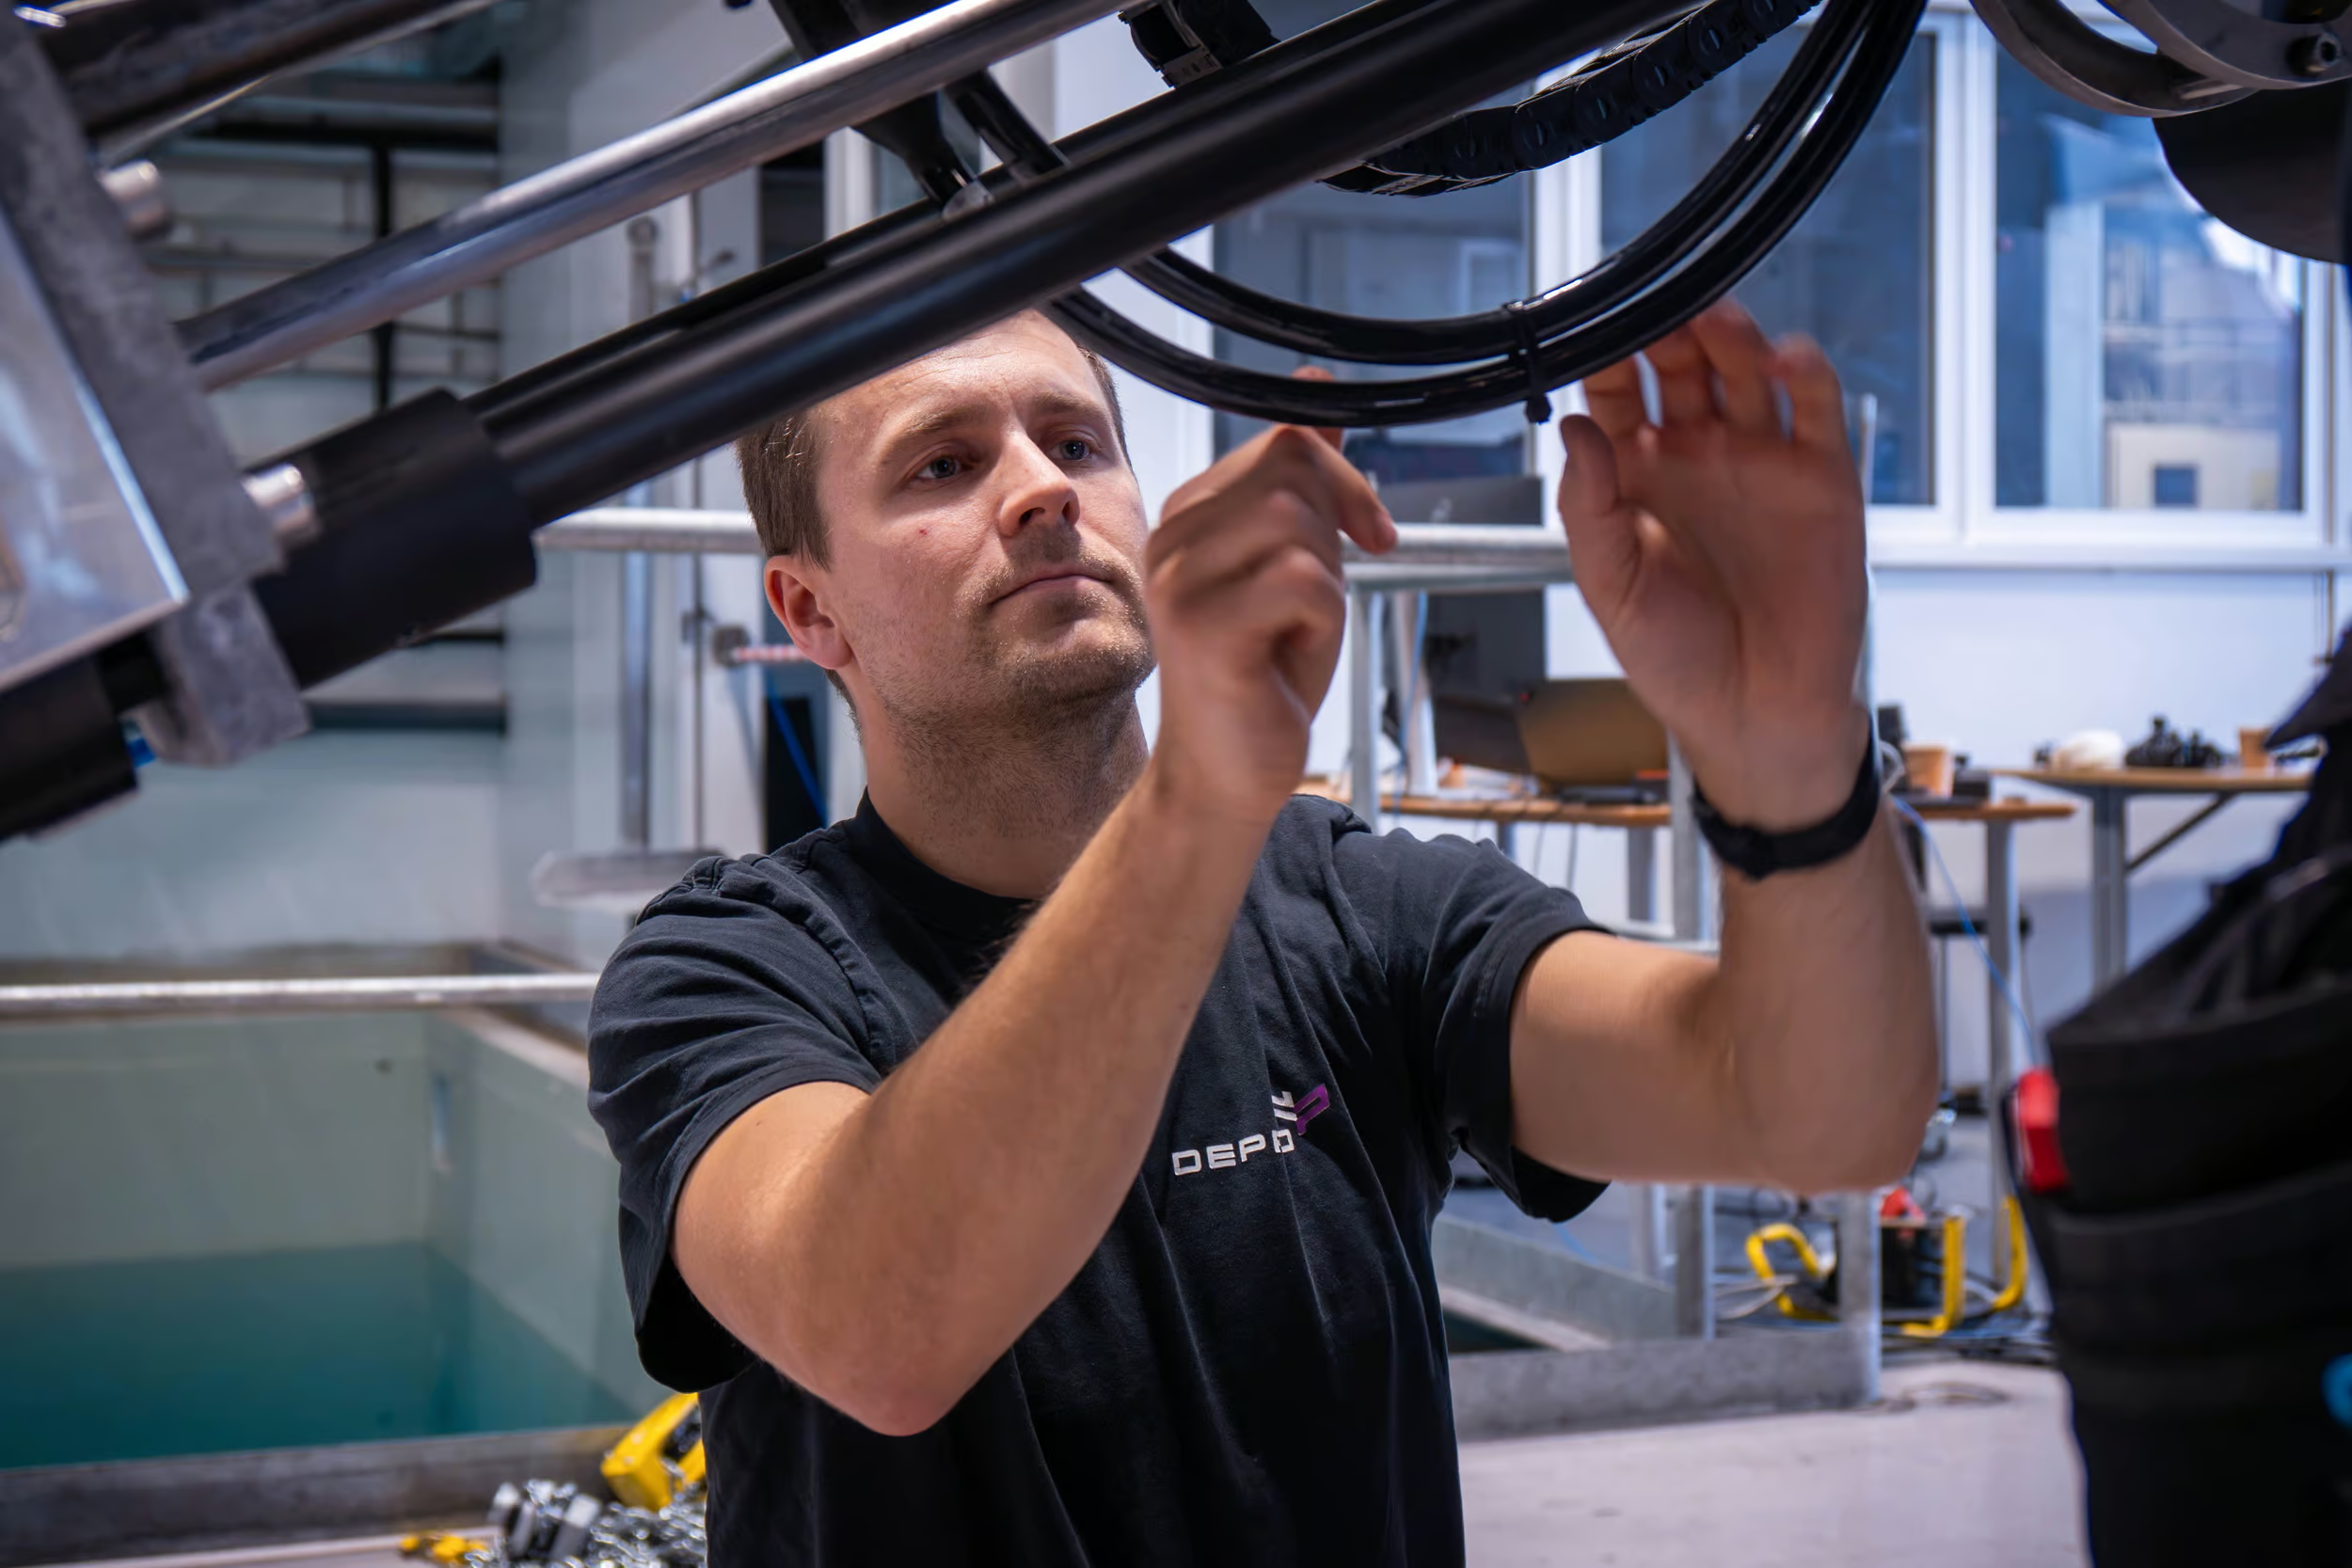
The accompanying video follows DEPRO’s team during mobilisation and integration of the SLS on a Maritime Robotics vessel made available through Equinor.
The work forms part of preparations for testing and demonstration at Equinor’s test centre at Kårstø, Norway, exploring the deployment and operation of ROVs from uncrewed vessels.
The aim is practical: to make commercial ROV operations more flexible to mobilise, easier to integrate and well equipped for subsea data collection.